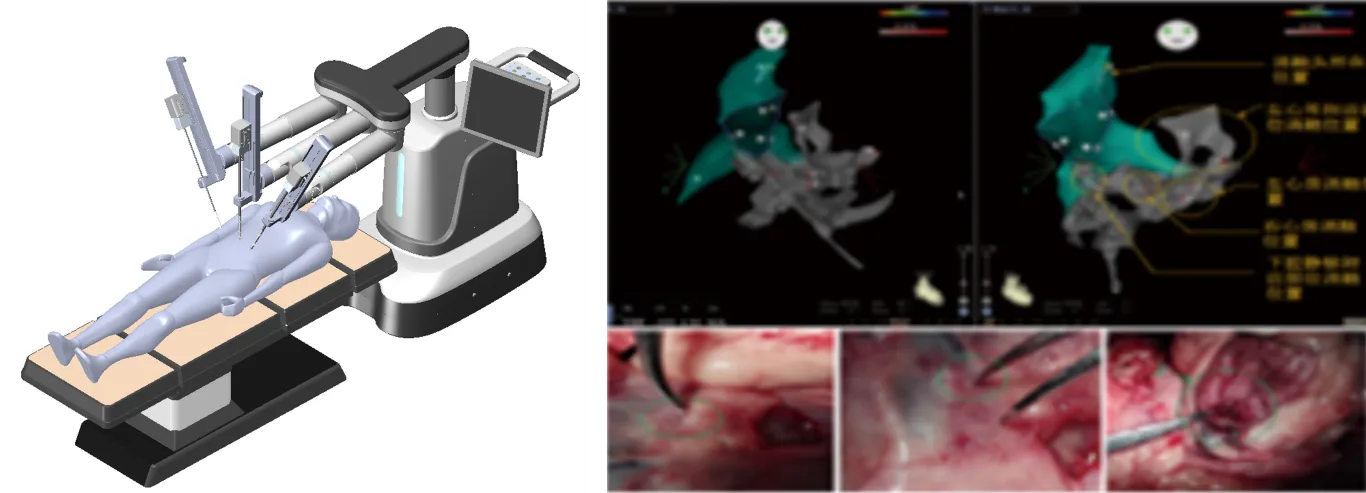
Autonomous Suture Robot System for Endoscopic Surgery
Vision-guided autonomous suturing for endoscopic surgery with a 3-DoF instrument.
The aim was to improve the efficiency and accuracy of autonomous suturing in endoscopic surgery: a 3-DoF suturing instrument, a laparoscopic robot that uses 3D laparoscopy, and a system that combines vision, expert knowledge, and navigation.
Instrument and lesion tissue were recognized and segmented with YOLOv8 so that the spatial position of the instrument tip could be recovered. A fused vision–arm stack performed hand–eye calibration and executed basic visual-servo motions.