Haofei Ma马浩飞
Robotics Researcher
Haptic Teleoperation · Force–Tactile Learning · Egocentric Robot Learning
I study MR-assisted haptic teleoperation, force–tactile skill learning, and how robots can acquire dexterous skills from first-person human demonstration.
Research
Explore research →- 01
MR-Assisted Haptic Robot Teleoperation
How can mixed-reality interfaces and haptic gloves transfer human intent and contact to remote robots?
- 02
Force–Tactile Robot Skill Learning
How can robots acquire contact-rich manipulation skills from force and tactile sensing?
- 03
Egocentric Robot Learning from Humans
How can robots learn dexterous skills from first-person human demonstration?
Selected Projects
All projects →HapticDP: Visuo-Haptic Diffusion Policy
Visuo-haptic policy learning for bimanual dexterous manipulation, with slow visual planning and faster force–tactile refinement during contact.
Glovity: Wearable Teleoperation (CobotAI)
CobotAI wearable teleoperation product—hand-pose capture, mapping onto robot arms and dexterous hands, and multimodal demonstration recording.
AR-Assisted Aircraft Drilling
Mixed-reality guidance for precision drilling on large structures, from a July 2025 demonstration in Wuxi.
Selected Publications
All publications →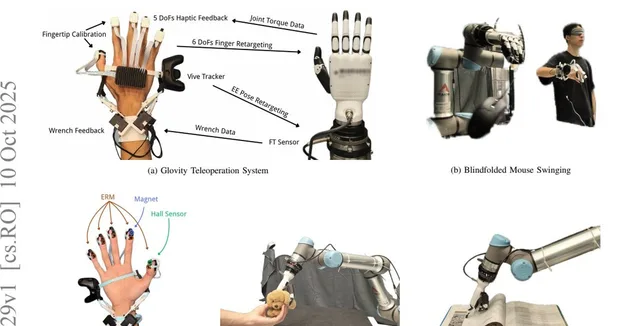
Glovity: Learning Dexterous Contact-Rich Manipulation via Spatial Wrench Feedback Teleoperation System
arXiv preprint arXiv:2510.09229 · 2025
A low-cost wearable teleoperation system with spatial wrench feedback and a fingertip-calibrated haptic glove for contact-rich dexterous manipulation.
News
All news →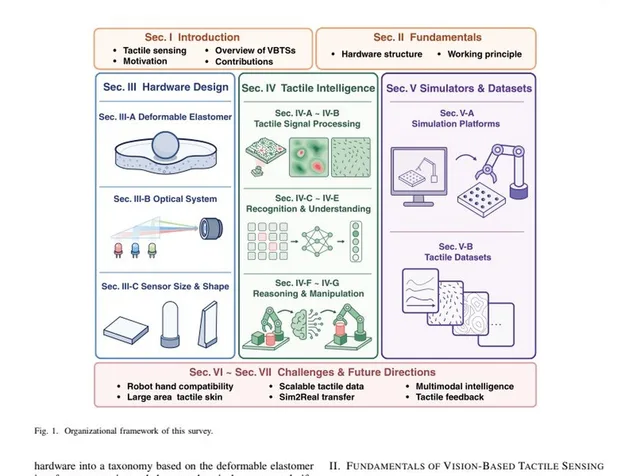 Survey on vision-based tactile intelligence for robotics posted on arXiv.
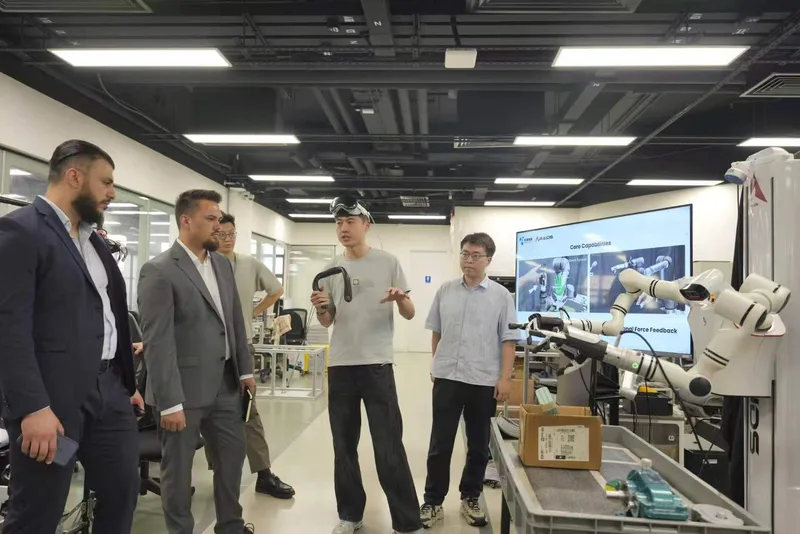 Demonstrated Vision Pro and ARAIOS teleoperation to visiting German industry representatives.
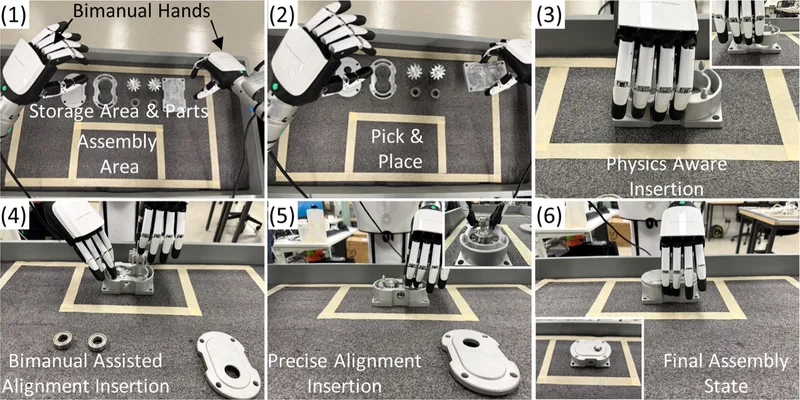
- Paper on bimanual dexterous assembly published in CIRP Annals.
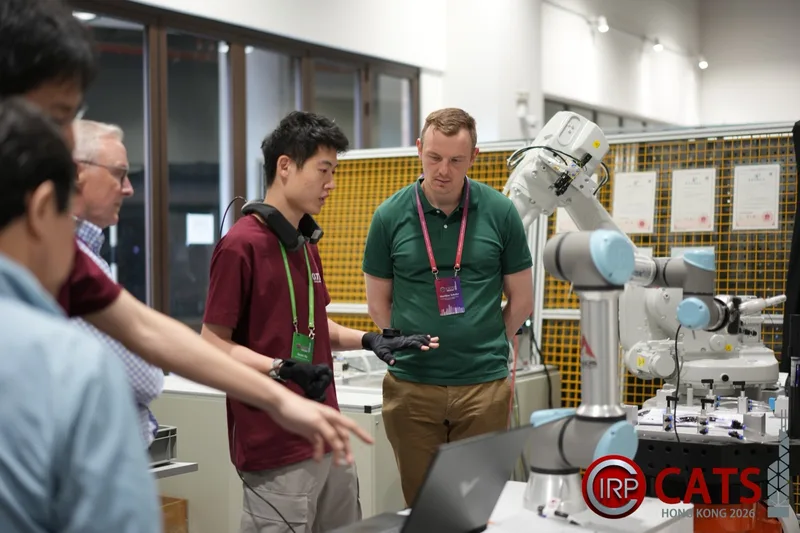 Demonstrated haptic teleoperation at CIRP CATS 2026, hosted at PolyU.
Recent Posts
All posts →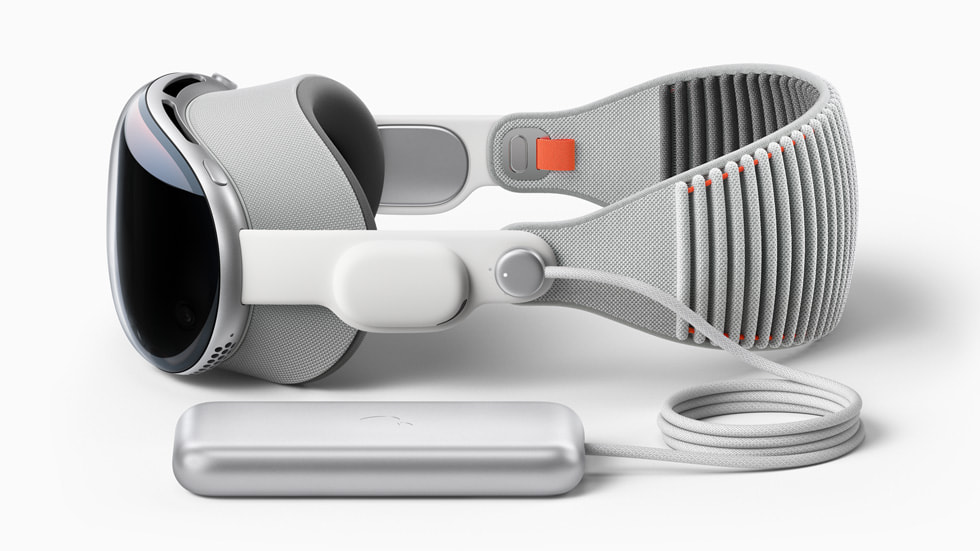
Getting Started with Apple Vision Pro Development
This article documents the complete process for setting up an Apple Vision Pro development environment, covering physical-device debugging with Xcode, Unity + PolySpatial configuration, Play to Device streaming, app packaging, and basic concepts such as visionOS space types and Volume Camera.
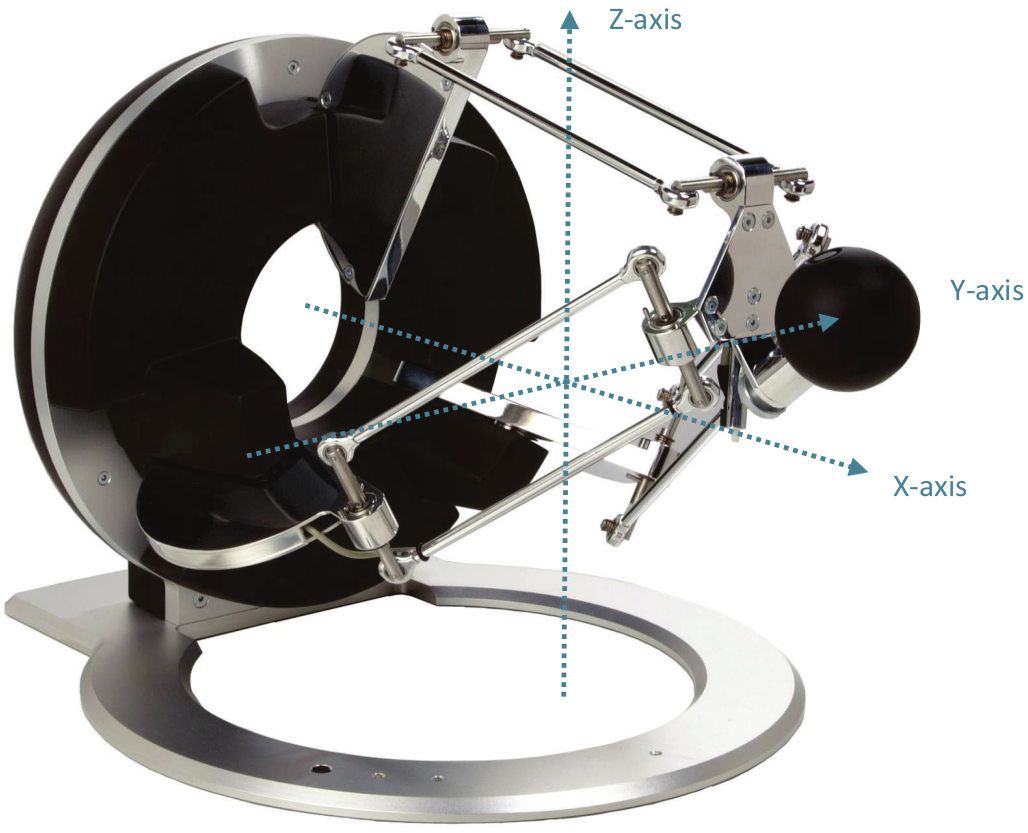
[Equipment Guide] omega.7 Master Device Setup and Usage
Configuration and basic program usage for the Omega.7 virtual haptic force-feedback master device
[Paper Notes] ACT: Imitation Learning for Bimanual Manipulation with Low-Cost Hardware
A Stanford University bimanual imitation learning system with a full hardware and software stack that enables fine manipulation on low-cost, imprecise hardware.
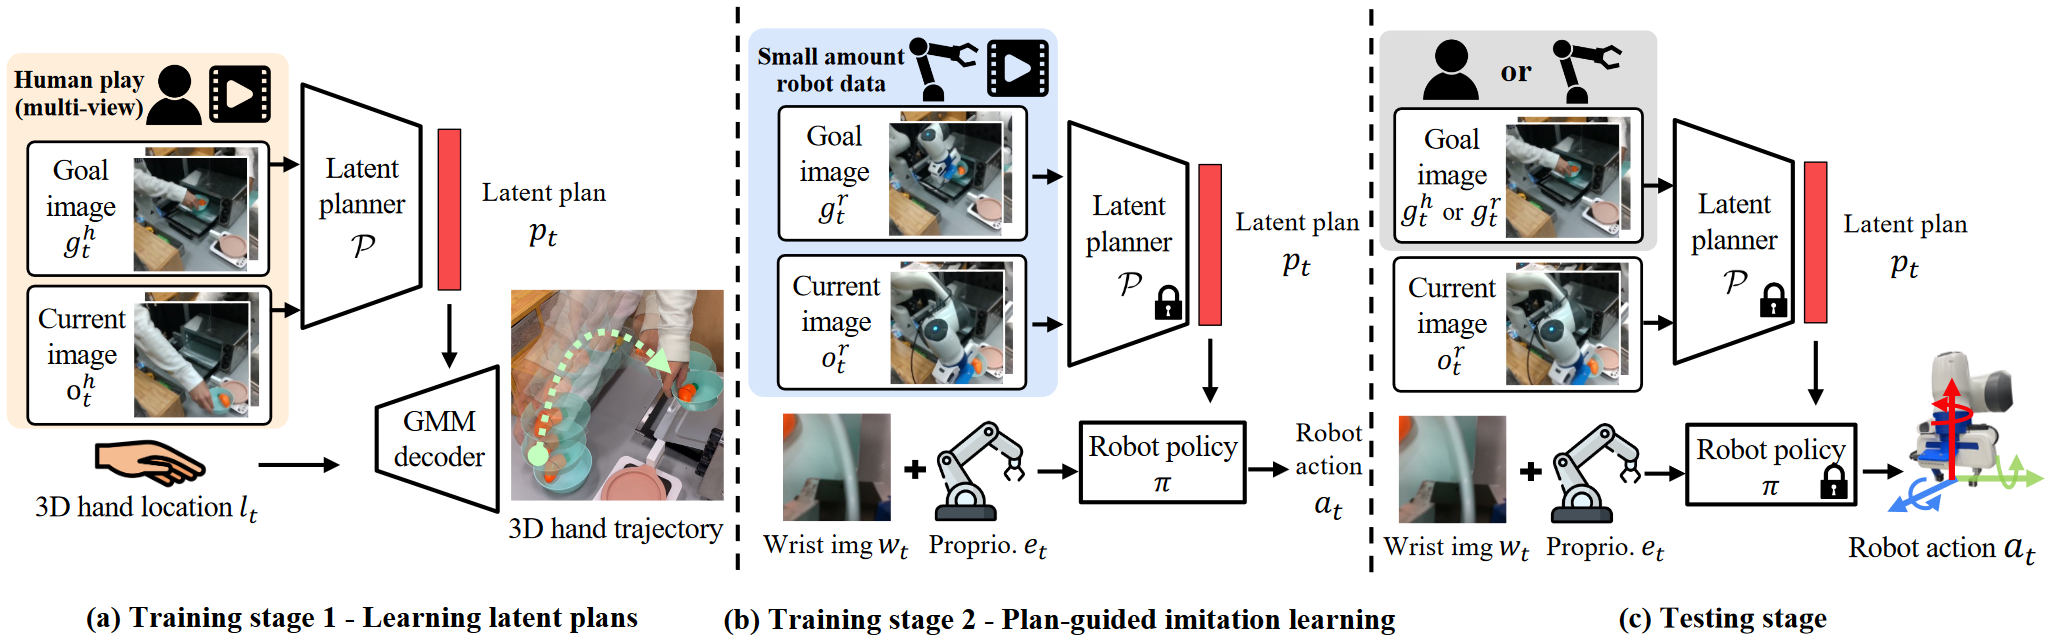
[Paper Reproduction] MimicPlay: Learning Robot Skills from Human Demonstrations
A long-horizon imitation learning method from Fei-Fei Li's team at Stanford University that learns by watching human actions.