Projects
Haptic teleoperation, visuo-haptic policy learning, mixed-reality guidance, and earlier robot platforms.
Featured / Current Research
HapticDP: Visuo-Haptic Diffusion Policy
Visuo-haptic policy learning for bimanual dexterous manipulation, with slow visual planning and faster force–tactile refinement during contact.
Glovity: Wearable Teleoperation (CobotAI)
CobotAI wearable teleoperation product—hand-pose capture, mapping onto robot arms and dexterous hands, and multimodal demonstration recording.
Completed Research
HKPC Parcel Unpacking
Robot unpacking of courier boxes, opening cartons and removing contents under human–robot collaboration.
AR-Assisted Aircraft Drilling
Mixed-reality guidance for precision drilling on large structures, from a July 2025 demonstration in Wuxi.
Bimanual Teleoperation for Sorting
Remote sorting with a UR arm and a dual-arm robot, mapping human hand motion onto pick-and-place in cluttered bins.
6D Grasp with Point Cloud Fusion
Model-free 6D pose estimation and point-cloud completion for robotic grasping.
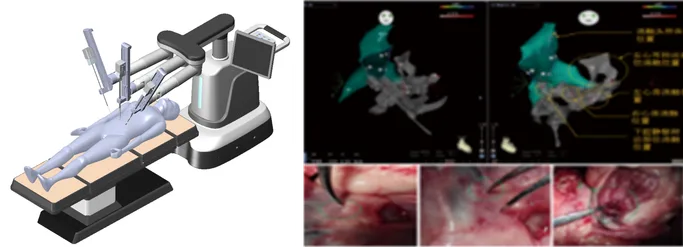
Autonomous Suture Robot System for Endoscopic Surgery
Vision-guided autonomous suturing for endoscopic surgery with a 3-DoF instrument.
Earlier Projects
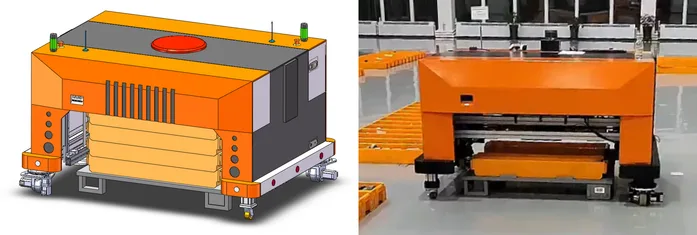
Rock Core Box Handling Robot
Sensing and visual servo for stacking and aligning heavy rock-core boxes on site.

Medical Pan-Tilt Control System Based on Binocular Vision
A multi-DoF pan-tilt that tracks clinicians and patients during procedures and rehabilitation.
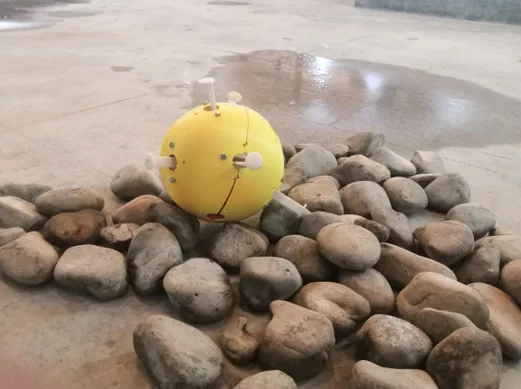
Spherical Environmental Information Collection Robot
A spherical metamorphic robot for monitoring hazardous sites with onboard environmental sensors.