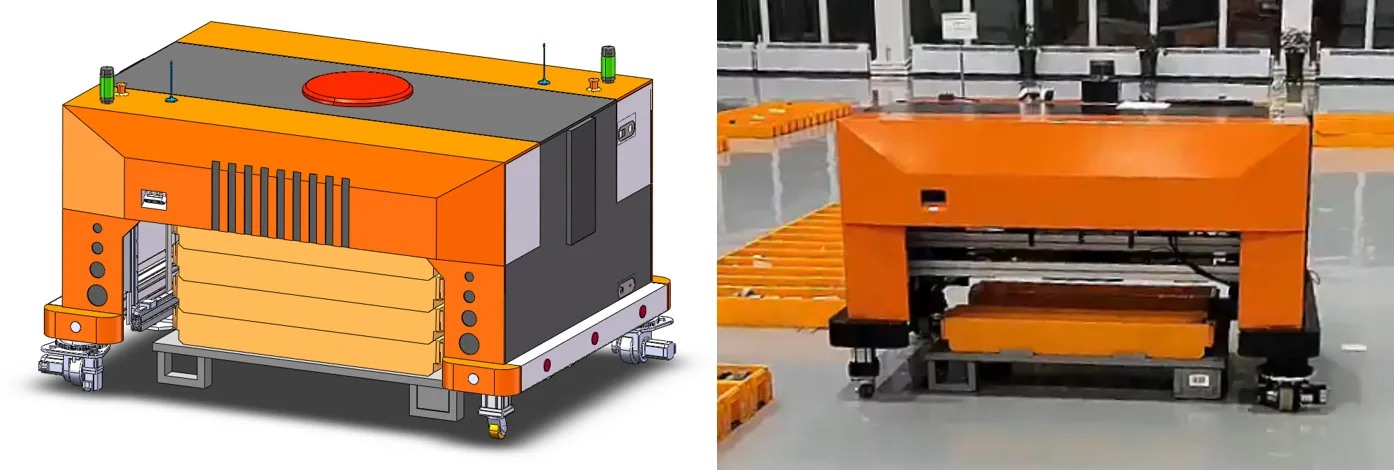
Rock Core Box Handling Robot
Sensing and visual servo for stacking and aligning heavy rock-core boxes on site.
Rock cores from exploratory drilling are stored in dedicated boxes. Those boxes have to be lined up on site in a prescribed order, one at a time, and they are heavy enough that manual handling is slow and exhausting. This project looked at a handling robot that could take over that stacking work.
The sensing stack used infrared sensors for nearby obstacles and a laser sensor for stack height and alignment. Mask R-CNN instance segmentation plus a depth camera recovered box-corner coordinates for visual servo. A monocular camera and ArUco markers measured planar offset and heading so the robot could correct its pose in place.