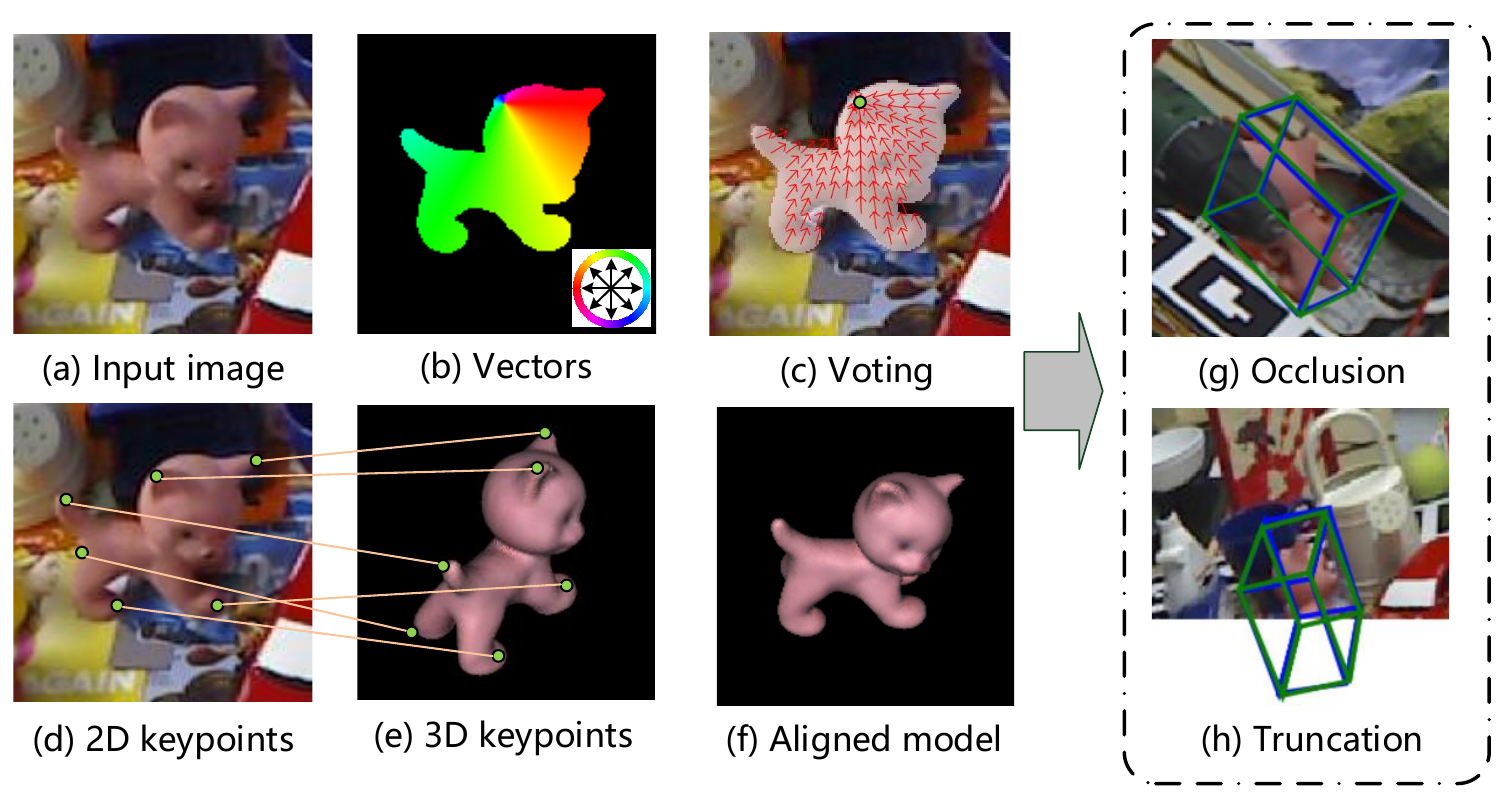
PVNet尚未跑通,暂时放弃。
标题:PVNet: Pixel-Wise Voting Network for 6DoF Pose Estimation 作者团队:浙江大学 期刊会议:CVPR 时间:2018 代码:https://zju3dv.github.io/pvnet/
环境搭建
(1)创建虚拟环境
创建conda环境
conda create -n pvnet python=3.7
conda activate pvnet

conda install pytorch==1.8.0 torchvision==0.9.0 torchaudio==0.8.0 cudatoolkit=11.1 -c pytorch -c conda-forge

pip install Cython==0.28.2
sudo apt-get install libglfw3-dev libglfw3注释掉requirement.txt中numpy和ipdb的版本限制,然后
pip install -r requirements.txt(2)编译扩展程序
创建环境变量
export CUDA_HOME="/usr/local/cuda-11.6"cd lib/cscr编译ransac_voting
cd ransac_voting
python setup.py build_ext --inplace
编译nn
cd ../nn
python setup.py build_ext --inplace
编译fps
cd ../fps
python setup.py build_ext --inplace
准备数据集
使用Objectdatasettools创建数据集,并按照下面的格式整理:
整理好后的文件参考:此文件
├── /path/to/dataset
│   ├── model.ply
│   ├── camera.txt
│   ├── diameter.txt  // the object diameter, whose unit is meter
│   ├── rgb/
│   │   ├── 0.jpg
│   │   ├── ...
│   │   ├── 1234.jpg
│   │   ├── ...
│   ├── mask/
│   │   ├── 0.png
│   │   ├── ...
│   │   ├── 1234.png
│   │   ├── ...
│   ├── pose/
│   │   ├── pose0.npy
│   │   ├── ...
│   │   ├── pose1234.npy
│   │   ├── ...
│   │   └──
创建软连接
ln -s /path/to/custom_dataset data/custom处理数据集
python run.py --type custom如果出现
ValueError: shapes (8,4) and (3,3) not aligned: 4 (dim 1) != 3 (dim 0)的问题 修改lib/utils/base_utils第23行如下xyz = np.dot(xyz, RT[:3, :3].T) + RT[:3, 3:].T
评论