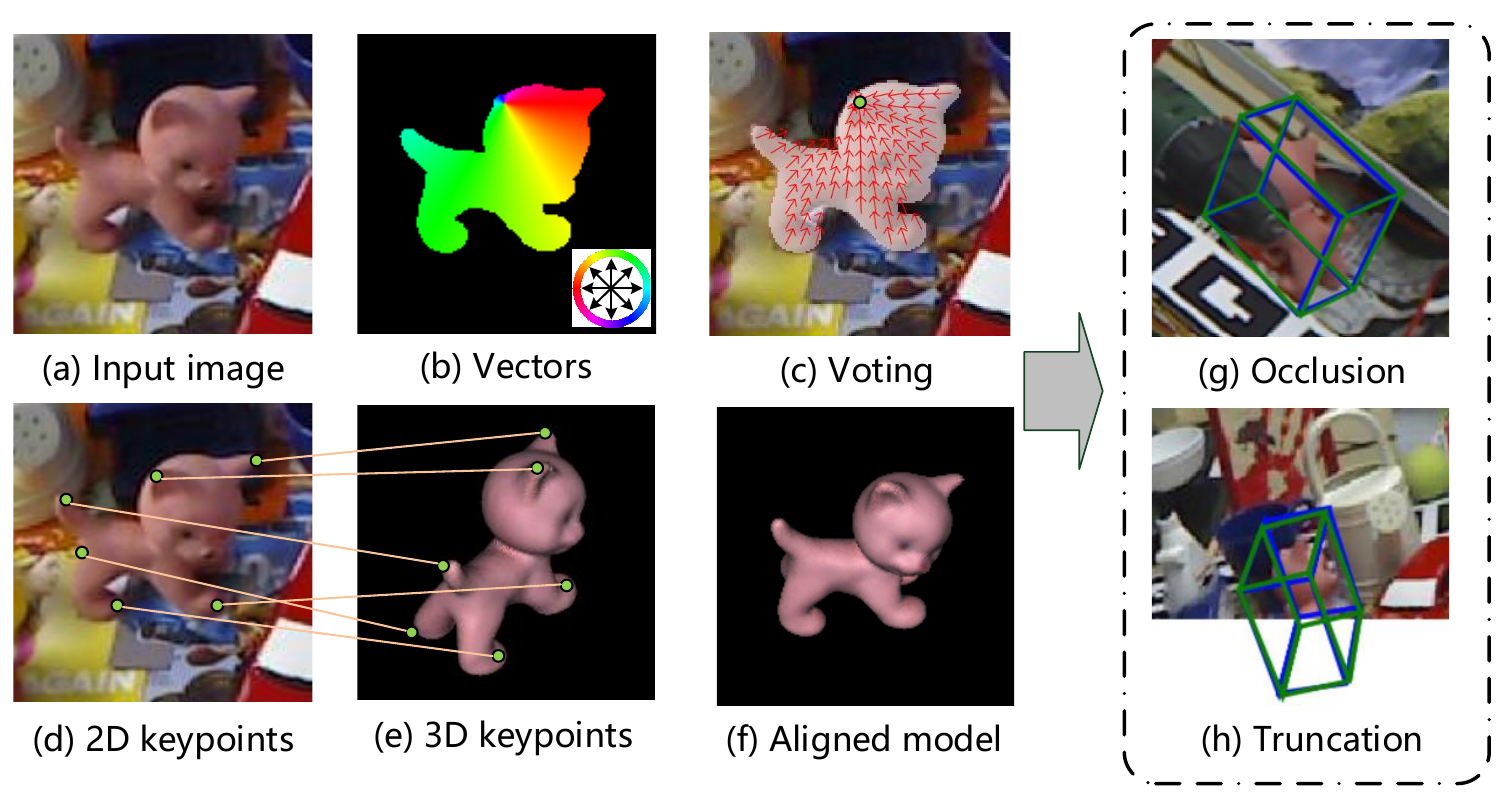
I haven’t gotten PVNet running yet, so I’m setting it aside for now.
Title: PVNet: Pixel-Wise Voting Network for 6DoF Pose Estimation Authors: Zhejiang University Conference: CVPR Year: 2018 Code: https://zju3dv.github.io/pvnet/
Environment Setup
(1) Create a virtual environment
Create a conda environment
conda create -n pvnet python=3.7
conda activate pvnet

conda install pytorch==1.8.0 torchvision==0.9.0 torchaudio==0.8.0 cudatoolkit=11.1 -c pytorch -c conda-forge

pip install Cython==0.28.2
sudo apt-get install libglfw3-dev libglfw3
In requirement.txt, comment out the version pins for numpy and ipdb, then
pip install -r requirements.txt(2) Compile extensions
Create environment variables
export CUDA_HOME="/usr/local/cuda-11.6"cd lib/cscrCompile ransac_voting
cd ransac_voting
python setup.py build_ext --inplace
Compile nn
cd ../nn
python setup.py build_ext --inplace
Compile fps
cd ../fps
python setup.py build_ext --inplace
Prepare the Dataset
Use Objectdatasettools to create the dataset and organize it in the following format:
For a reference of the prepared files, see this file
├── /path/to/dataset
│   ├── model.ply
│   ├── camera.txt
│   ├── diameter.txt  // the object diameter, whose unit is meter
│   ├── rgb/
│   │   ├── 0.jpg
│   │   ├── ...
│   │   ├── 1234.jpg
│   │   ├── ...
│   ├── mask/
│   │   ├── 0.png
│   │   ├── ...
│   │   ├── 1234.png
│   │   ├── ...
│   ├── pose/
│   │   ├── pose0.npy
│   │   ├── ...
│   │   ├── pose1234.npy
│   │   ├── ...
│   │   └──
Create a symbolic link
ln -s /path/to/custom_dataset data/customProcess the dataset
python run.py --type customIf you encounter
ValueError: shapes (8,4) and (3,3) not aligned: 4 (dim 1) != 3 (dim 0)Modify line 23 inlib/utils/base_utilsas followsxyz = np.dot(xyz, RT[:3, :3].T) + RT[:3, 3:].T
Comments