【Grasping by Imitation】Learning Robotic Grasping from Human Demonstrations
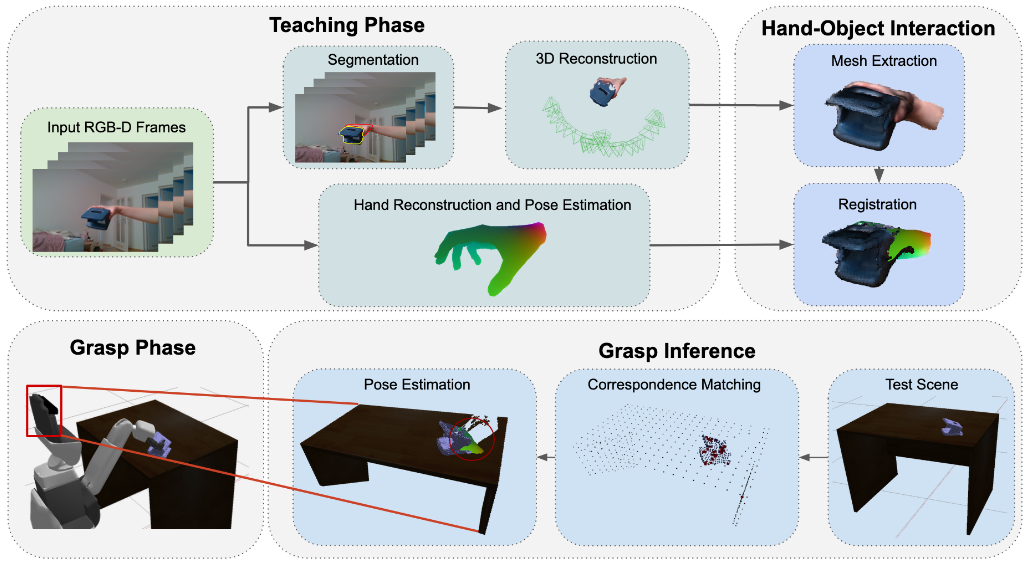
A survey of research on robotic grasping learned from videos of humans grasping objects.
4 posts
A survey of research on robotic grasping learned from videos of humans grasping objects.
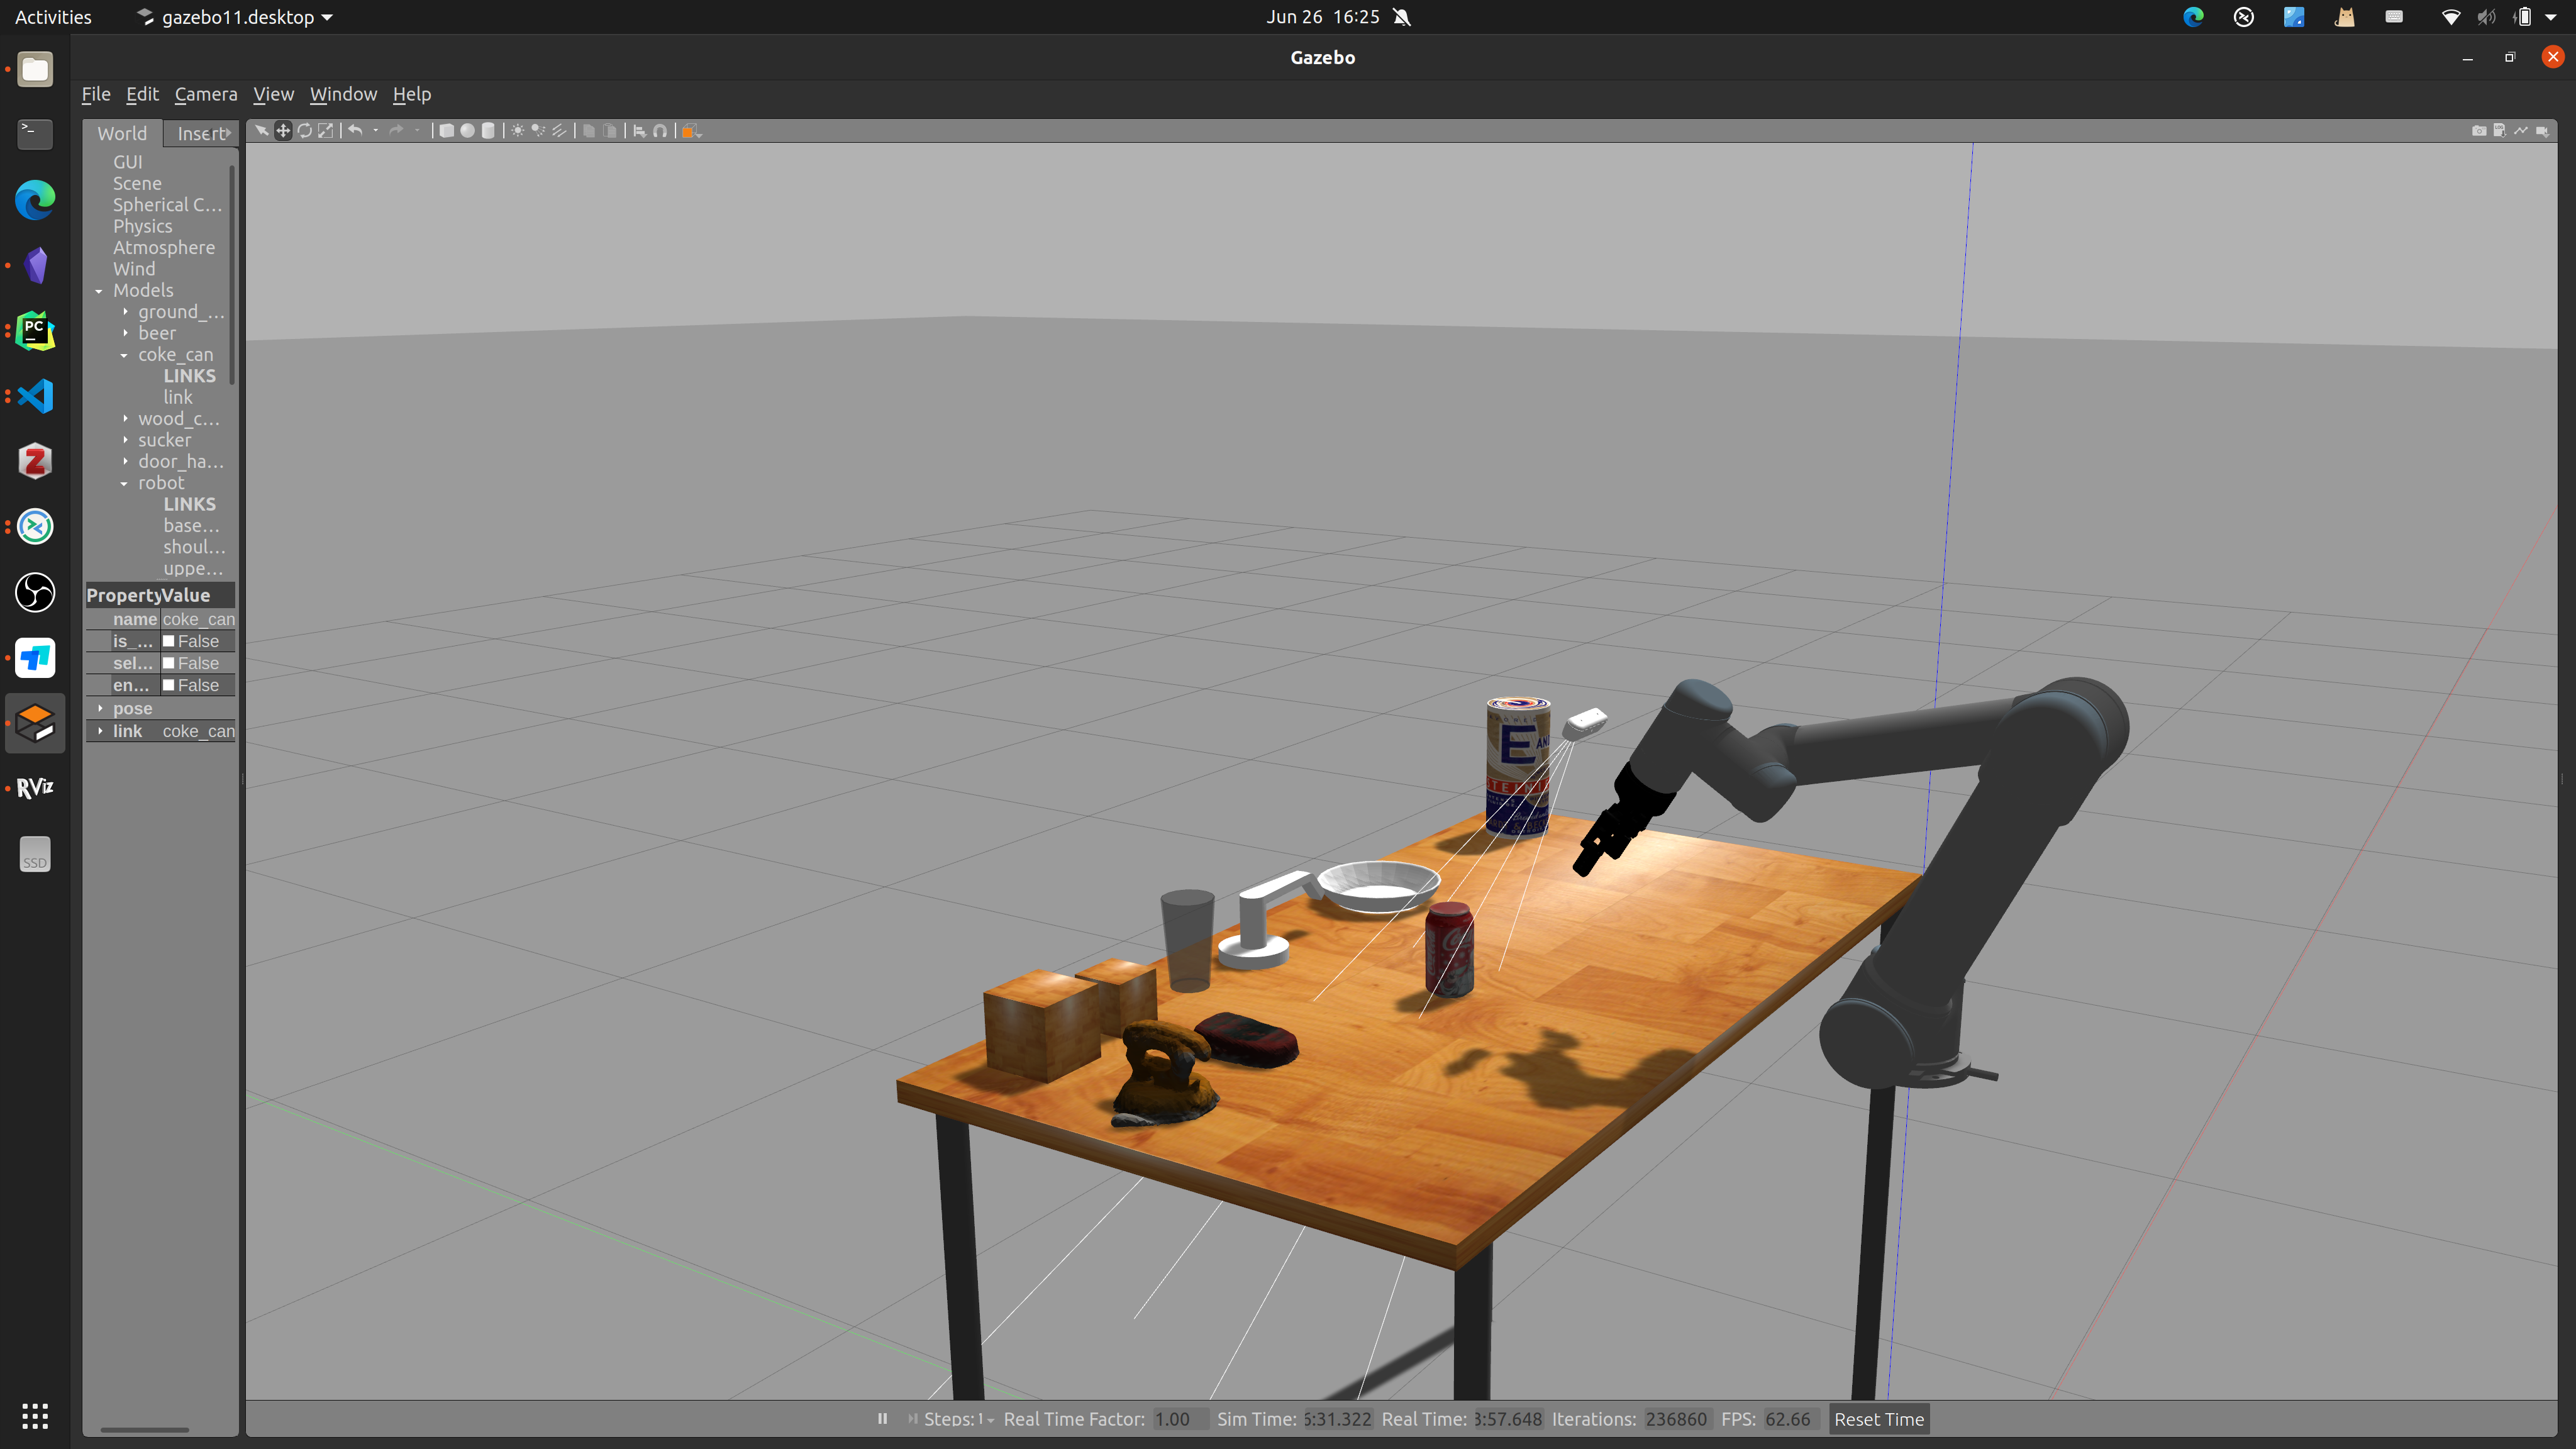
Build a 6D robotic arm simulation environment in Gazebo, add a camera, and implement a grasping simulation experiment.
Reproducing the RGB Matters algorithm proposed by Shanghai Jiao Tong University.
Reproducing Contact GraspNet, a grasp estimation algorithm proposed by NVIDIA