[Paper Notes] ACT: Imitation Learning for Bimanual Manipulation with Low-Cost Hardware
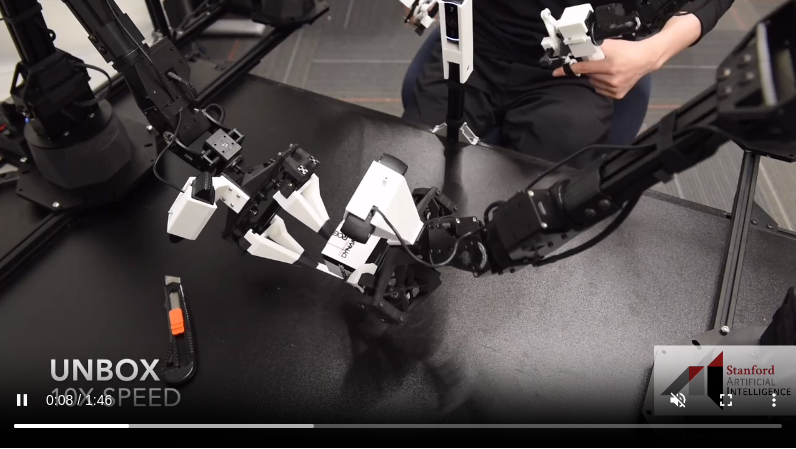
A Stanford University bimanual imitation learning system with a full hardware and software stack that enables fine manipulation on low-cost, imprecise hardware.
4 posts
A Stanford University bimanual imitation learning system with a full hardware and software stack that enables fine manipulation on low-cost, imprecise hardware.
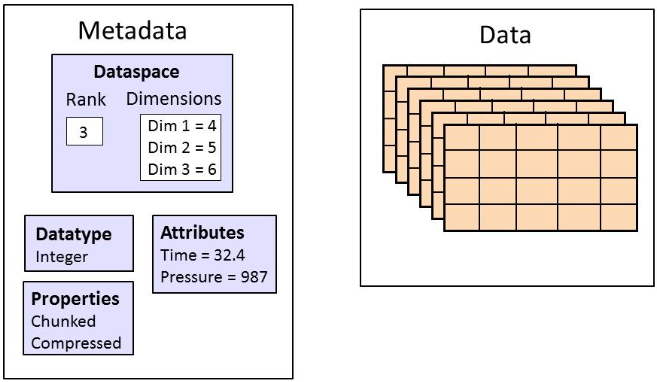
A brief introduction to the HDF5 data file format and its basic usage.
robomimic is a framework for robot learning from demonstrations. The project provides a range of demonstration data for robot manipulation and offline learning algorithms, enabling standardized testing of tasks and algorithms.
A lecture from Stanford CS25 V2 on robot learning, presented by a Google Brain engineer.