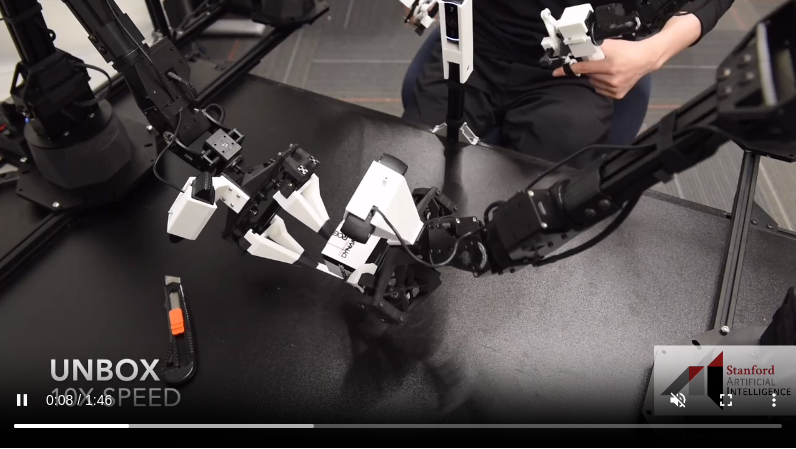
[Paper Notes] ACT: Imitation Learning for Bimanual Manipulation with Low-Cost Hardware
A Stanford University bimanual imitation learning system with a full hardware and software stack that enables fine manipulation on low-cost, imprecise hardware.
9 posts
A Stanford University bimanual imitation learning system with a full hardware and software stack that enables fine manipulation on low-cost, imprecise hardware.
robomimic is a framework for robot learning from demonstrations. The project provides a range of demonstration data for robot manipulation and offline learning algorithms, enabling standardized testing of tasks and algorithms.
A lecture from Stanford CS25 V2 on robot learning, presented by a Google Brain engineer.
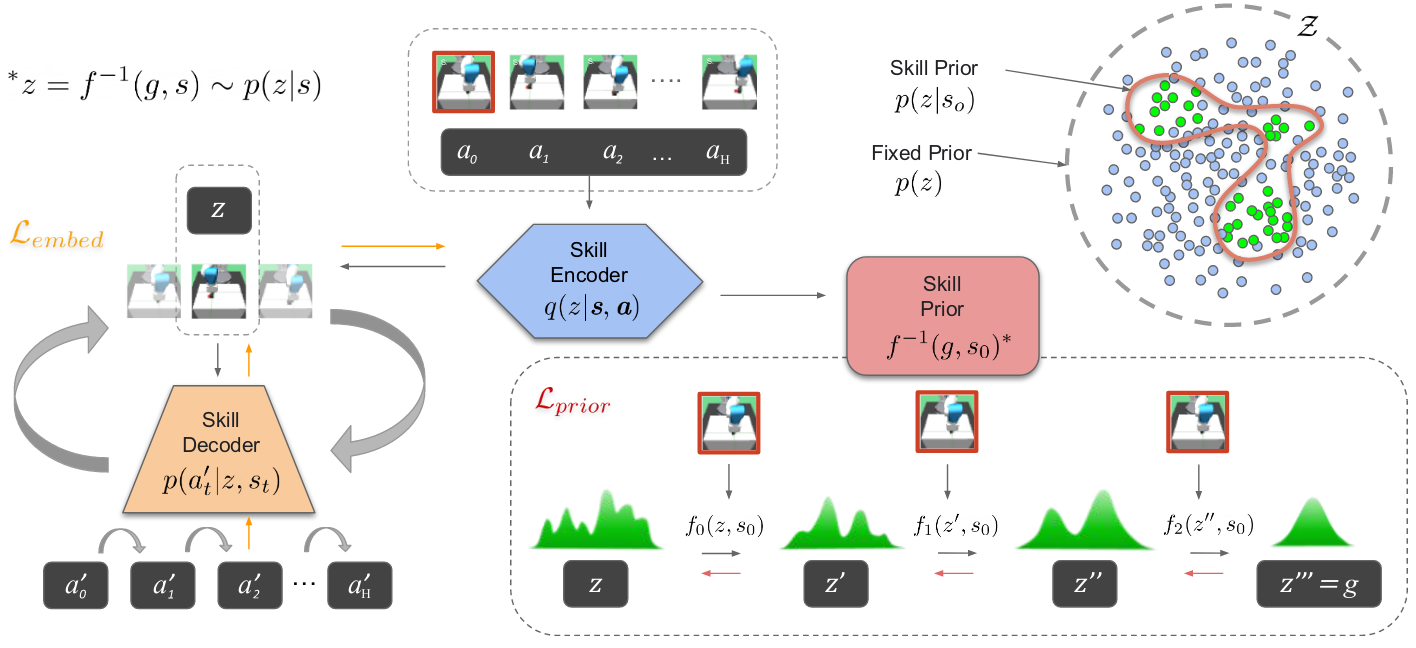
A skill-unit-based reinforcement learning method that decomposes tasks into skills, establishes mappings between skills and states, and learns a skill-selection policy
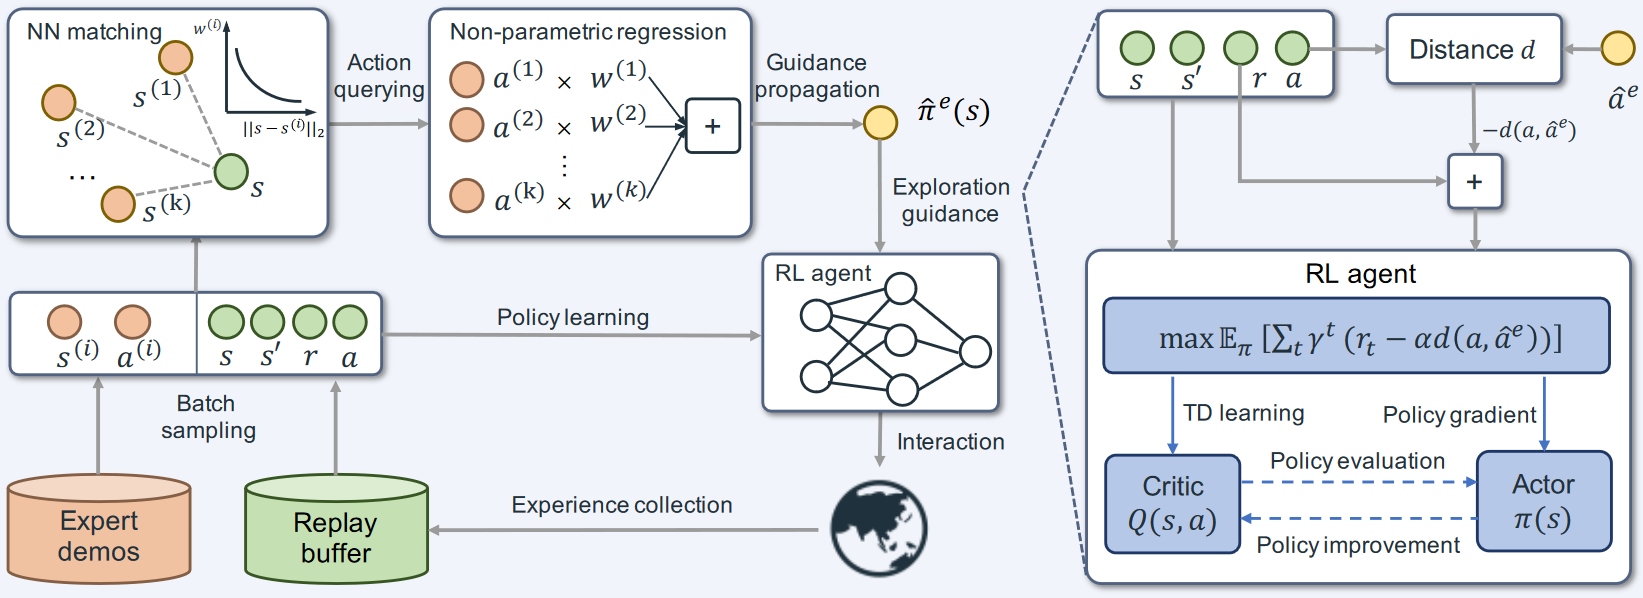
A surgical robot reinforcement learning method based on an improved DDPG+BC approach, developed by Yun-Hui Liu's team at The Chinese University of Hong Kong
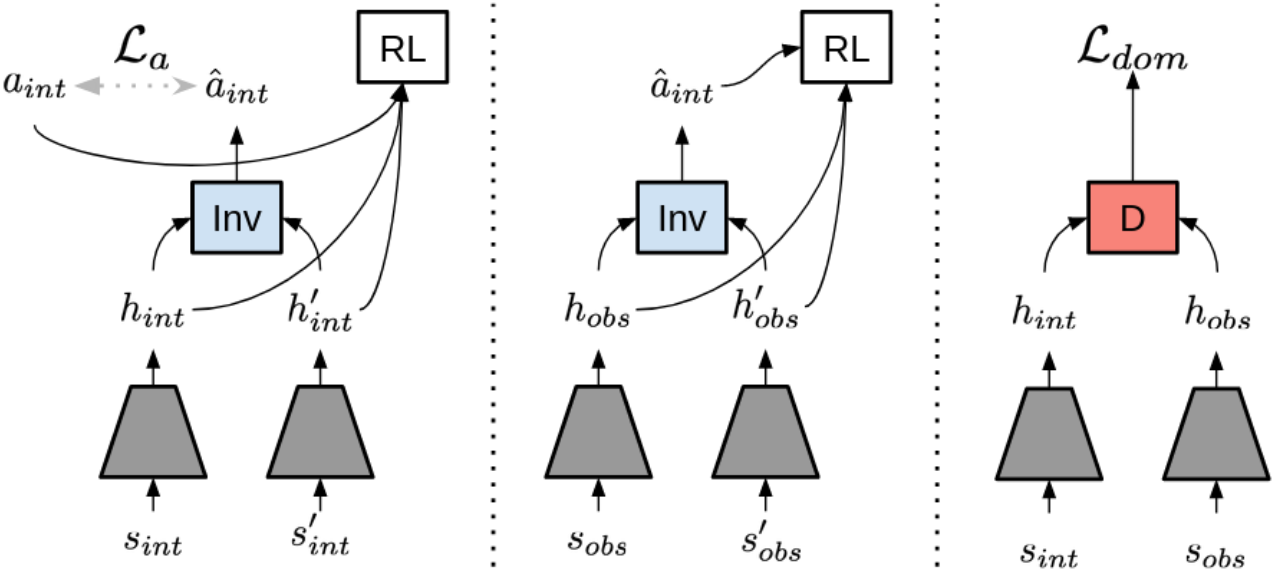
Survey and notes on reinforcement learning-based robot motion imitation methods.
A long-horizon imitation learning method from Fei-Fei Li's team at Stanford University that learns by watching human actions.
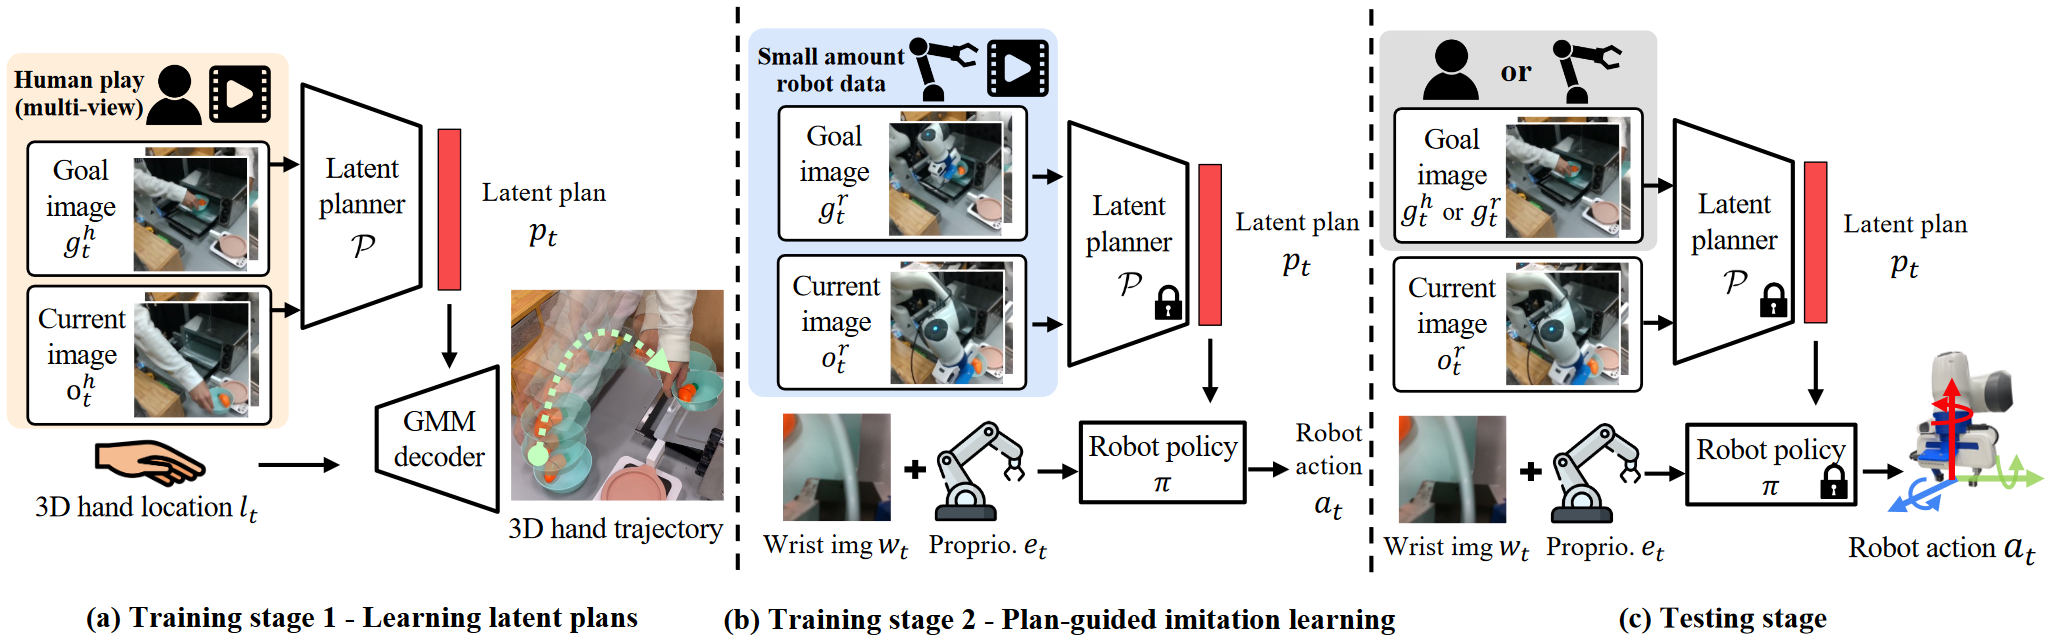
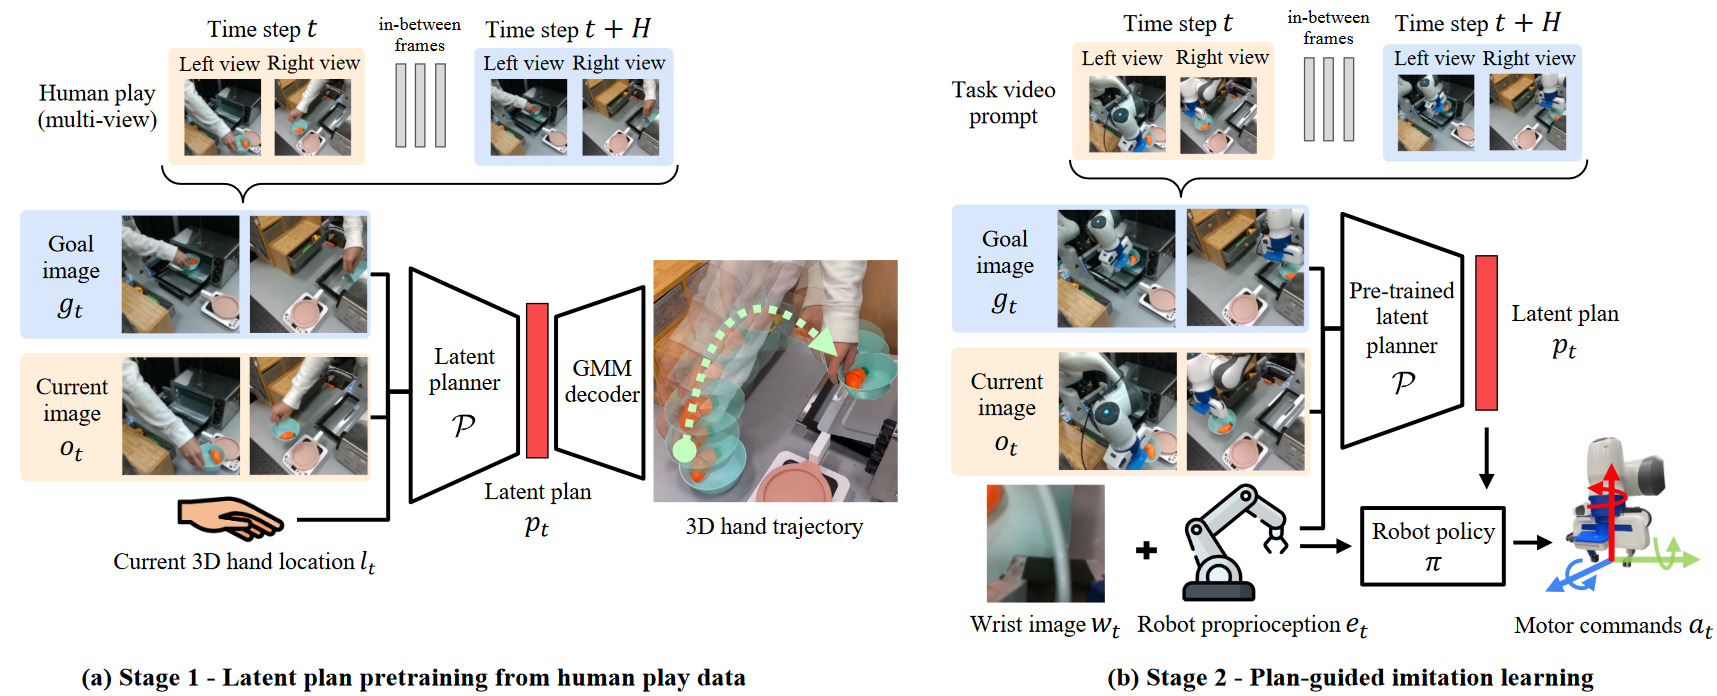
A survey of research on methods for robot motion generation and planning learned from videos of humans grasping objects.
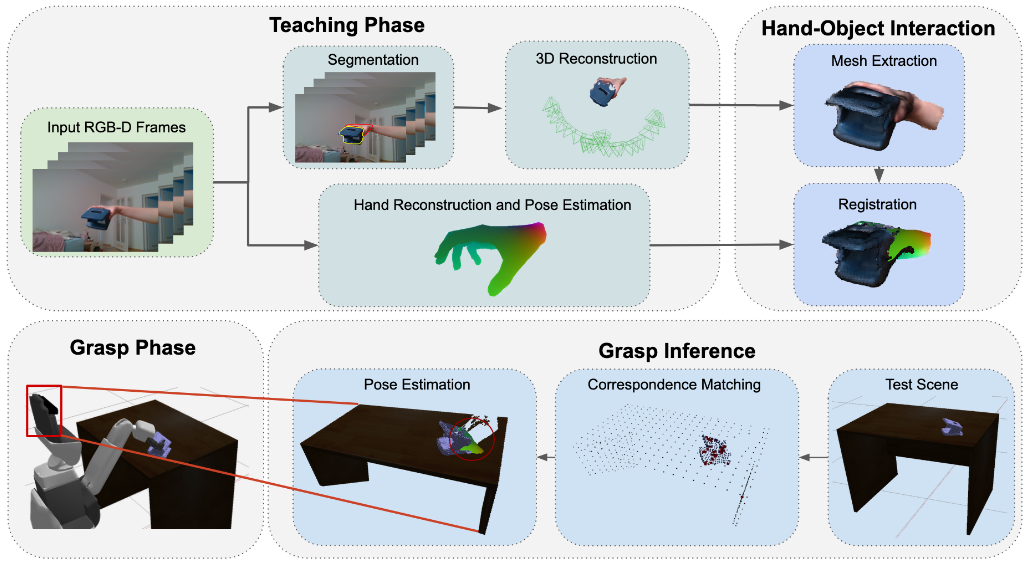
A survey of research on robotic grasping learned from videos of humans grasping objects.