ROS Gazebo 6D Robotic Arm Grasping Simulation Experiment
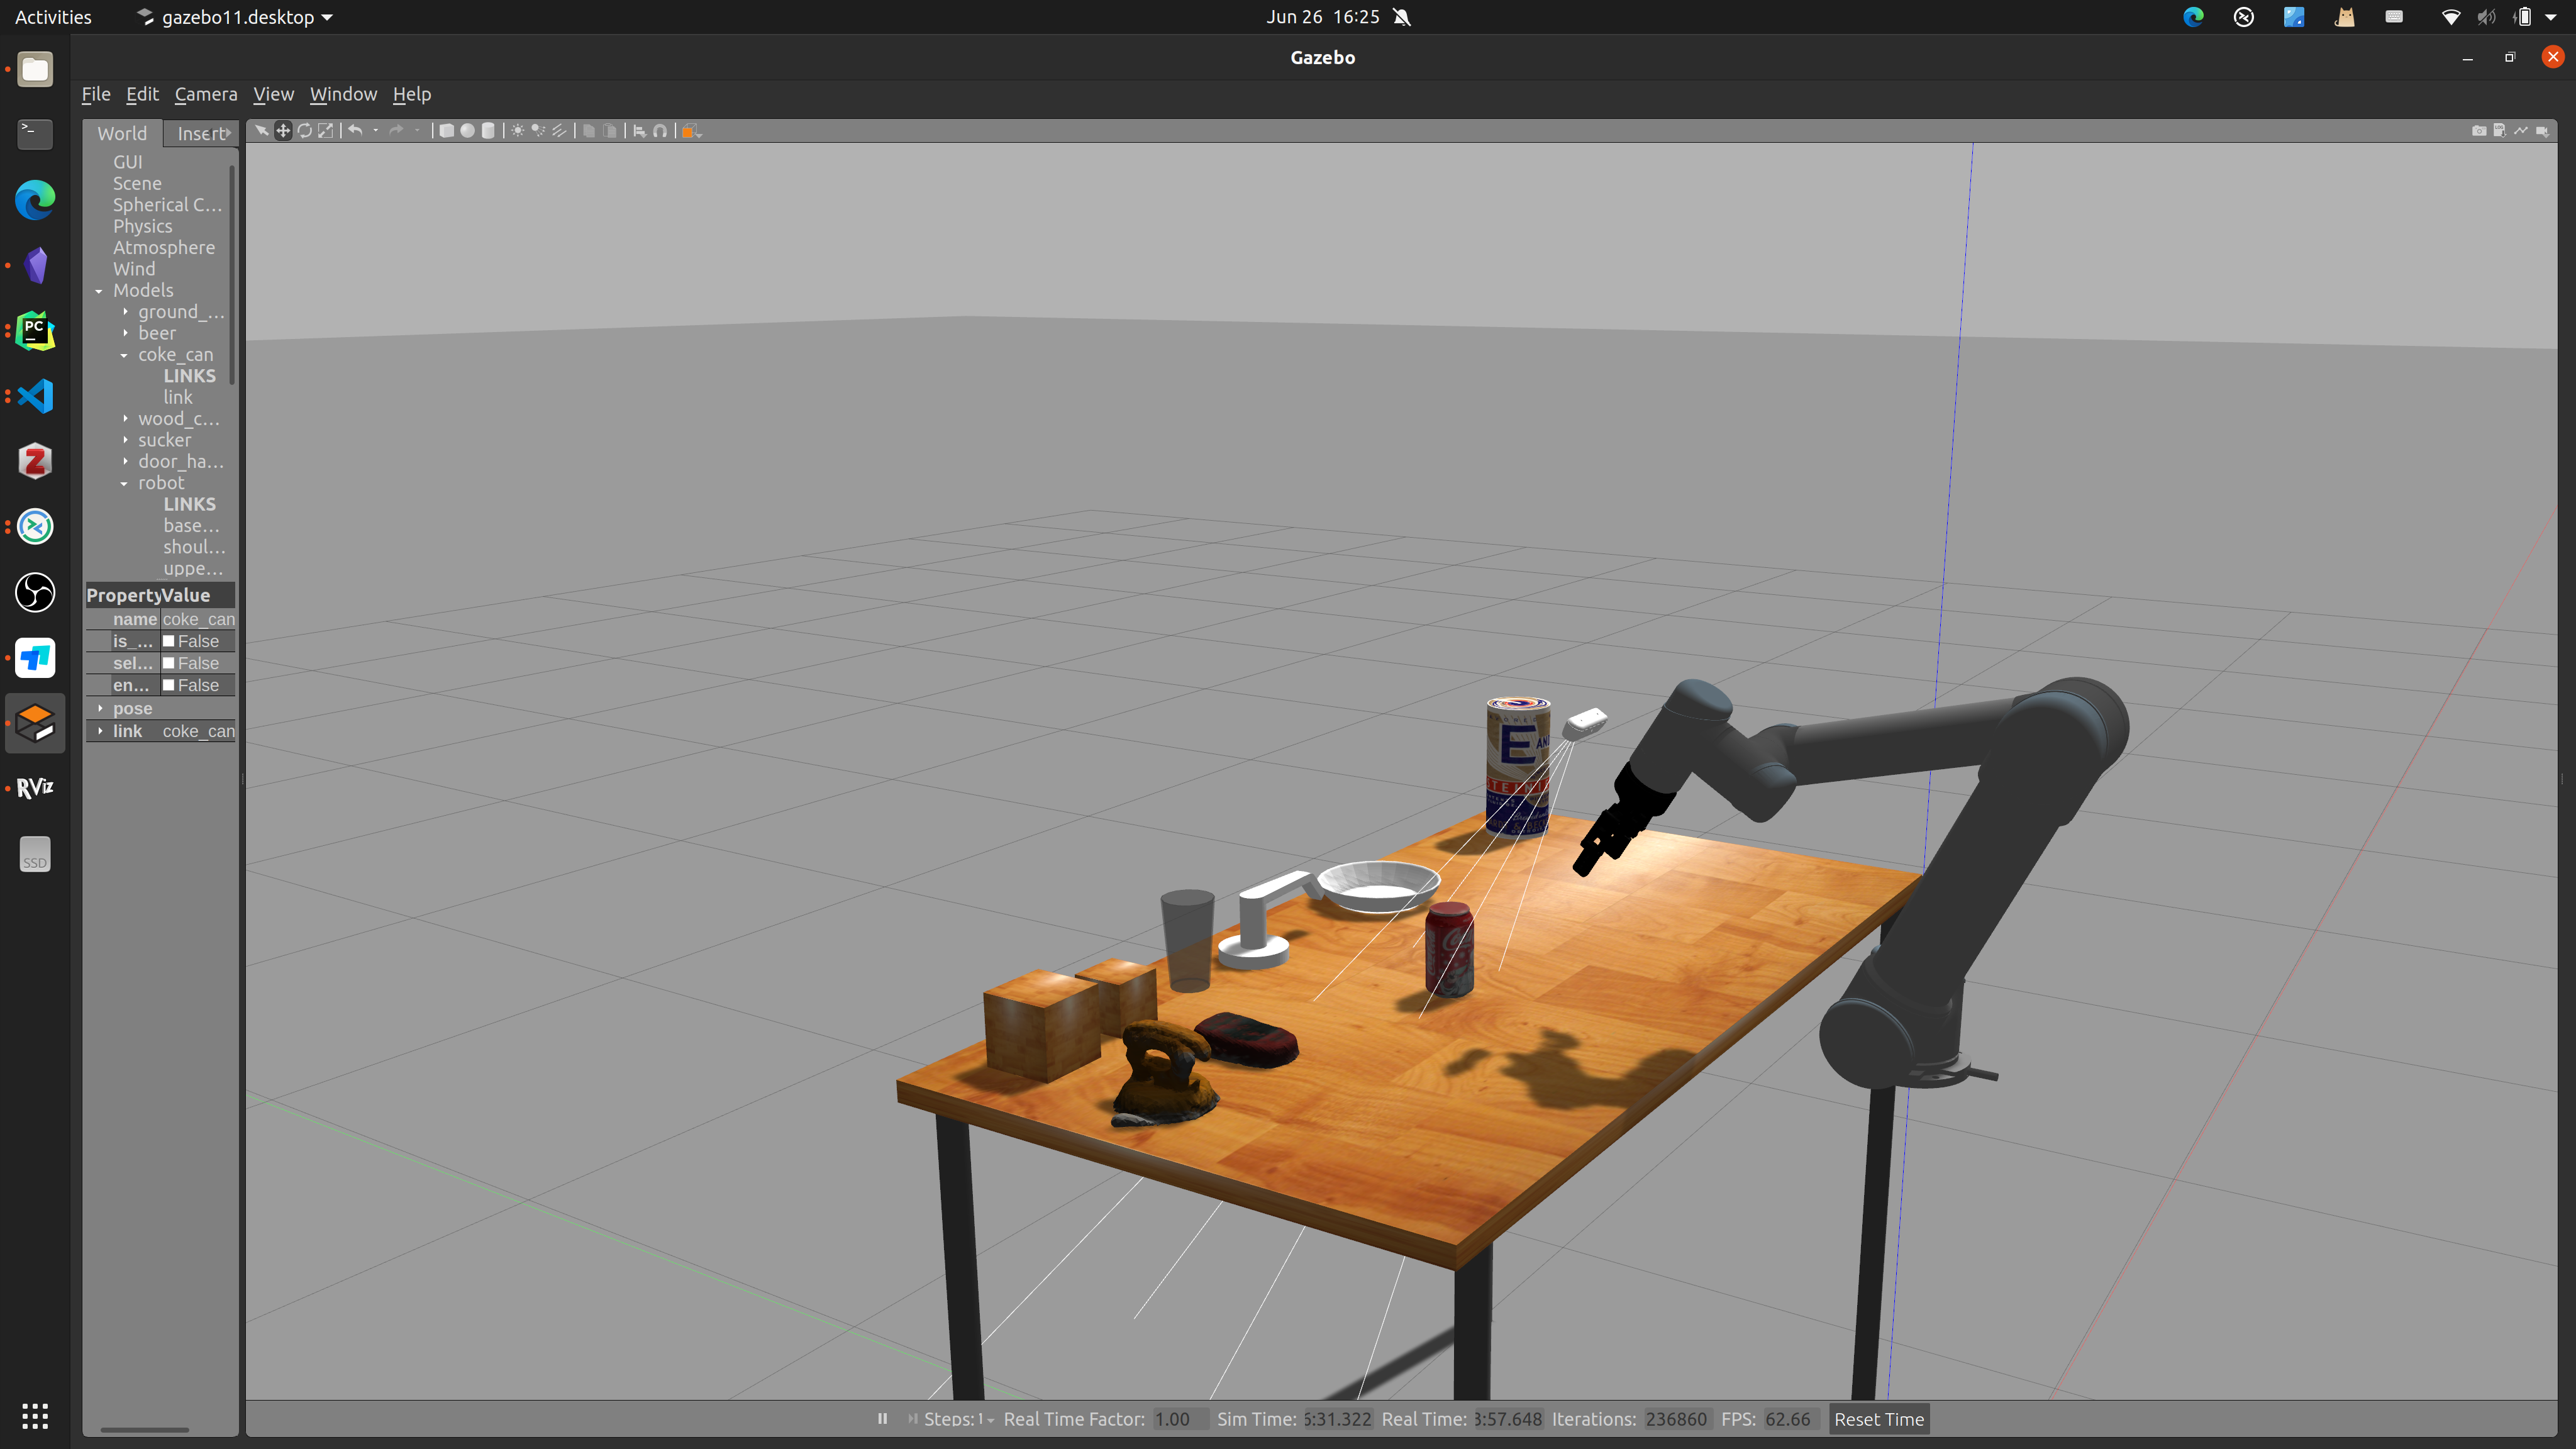
Build a 6D robotic arm simulation environment in Gazebo, add a camera, and implement a grasping simulation experiment.
4 posts
Build a 6D robotic arm simulation environment in Gazebo, add a camera, and implement a grasping simulation experiment.
Reproducing the RGB Matters algorithm proposed by Shanghai Jiao Tong University.
A survey of grasp pose estimation papers from top conferences and journals over the past three years
Reproducing Contact GraspNet, a grasp estimation algorithm proposed by NVIDIA