Installing and Using the PCL Library
The most widely used point cloud library in C++
4 posts
The most widely used point cloud library in C++
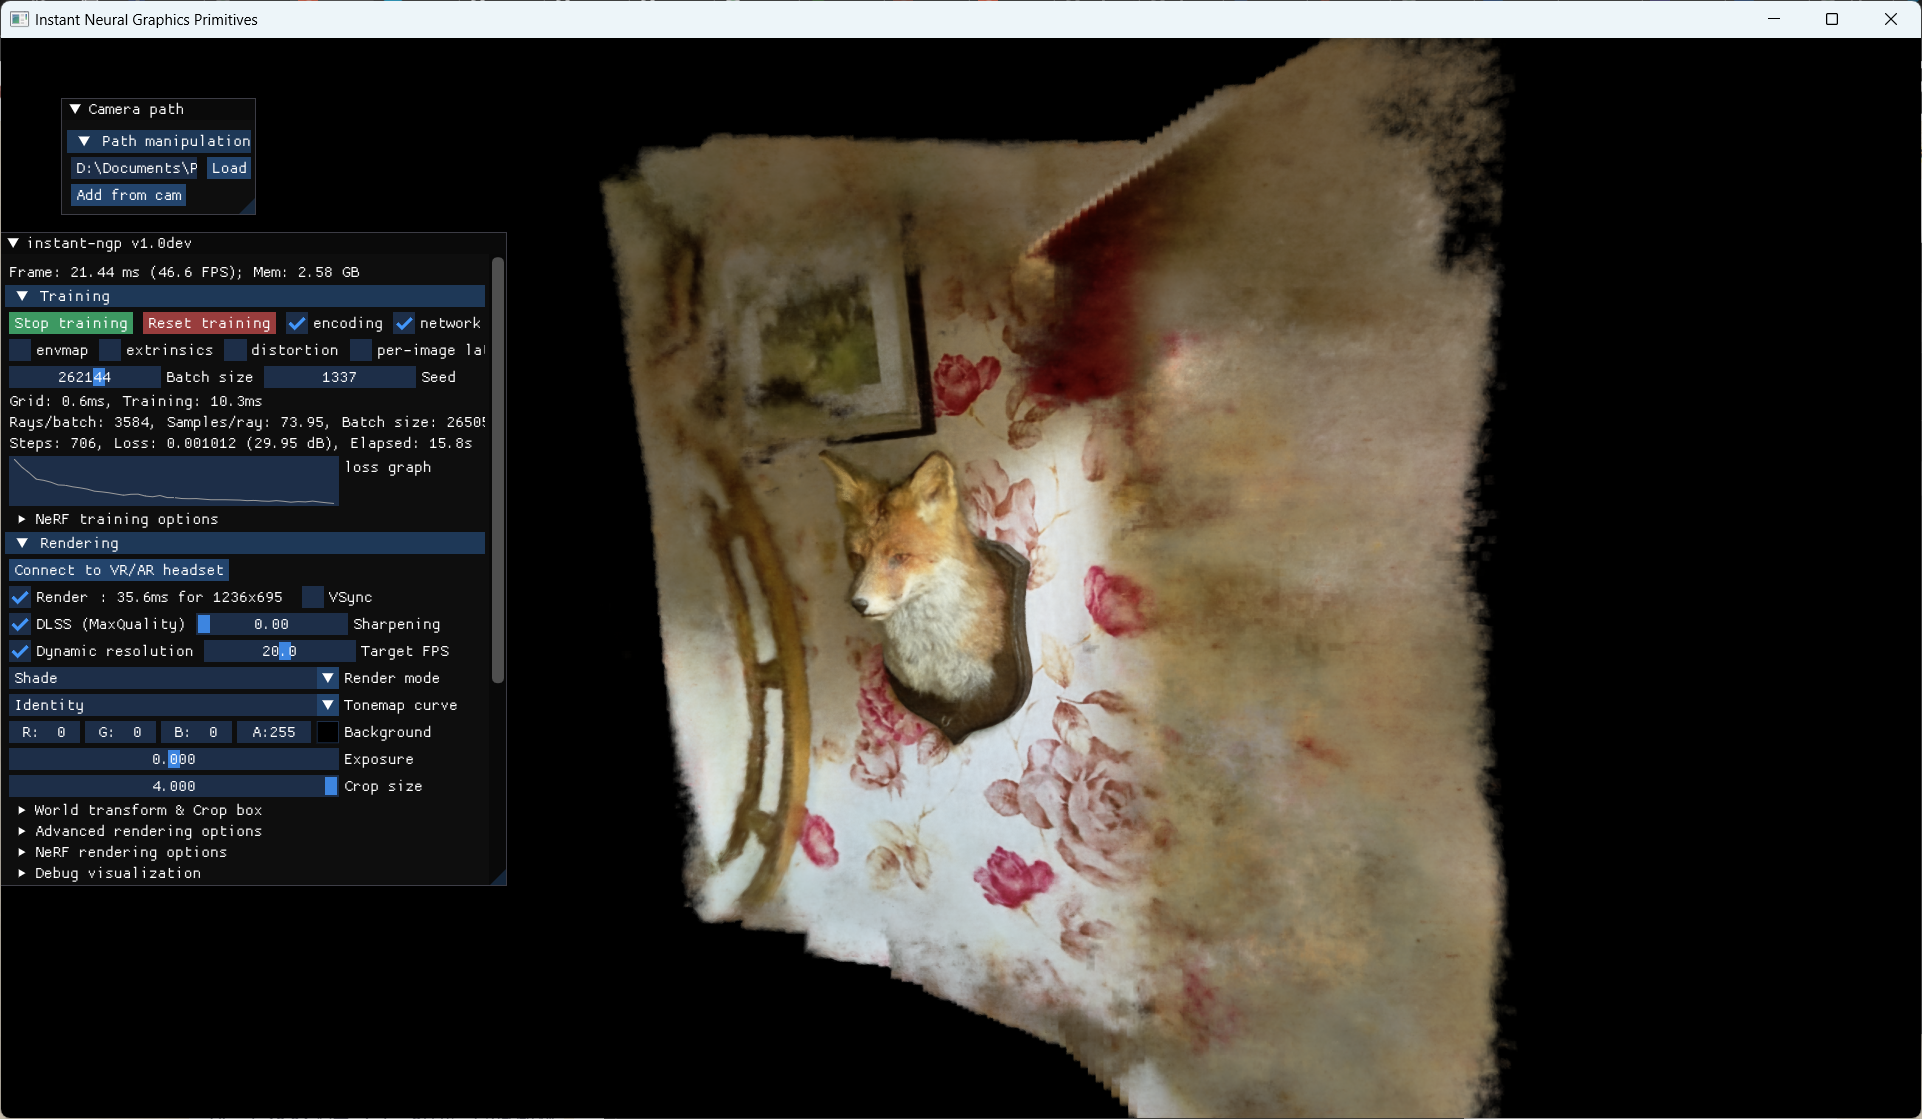
Instant-NGP, short for Instant Neural Graphics Primitives, uses multiresolution hash encoding to solve the efficiency problem encountered when parameterizing NeRF with a fully connected neural network. It greatly accelerates network training, reducing three-dimensional reconstruction time from several hours to several seconds.
COLMAP is a general-purpose Structure-from-Motion (SfM) and Multi-View Stereo (MVS) tool with graphical and command-line interfaces. OpenMVS is one of the three-dimensional reconstruction frameworks that produces better reconstruction results, and it provides automated scripts.
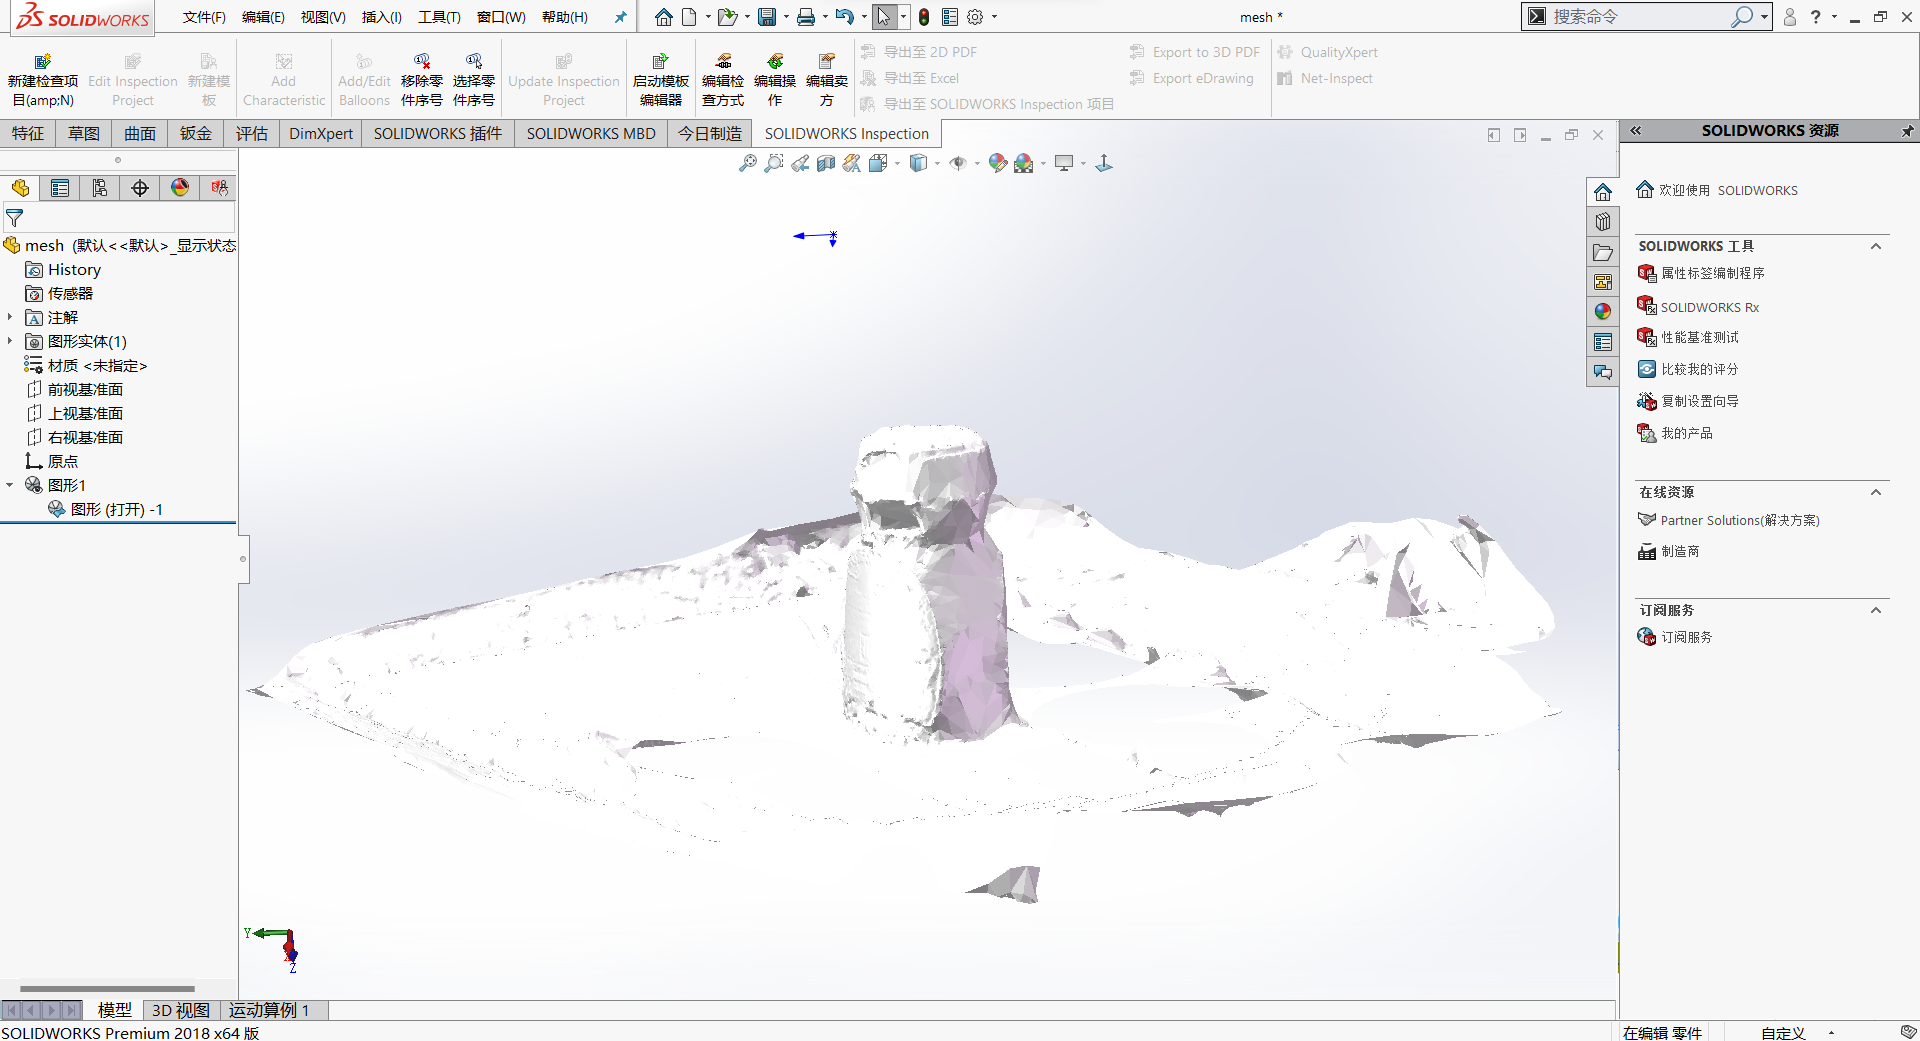
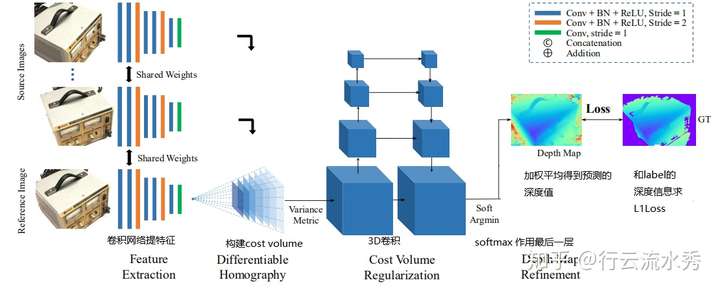
Three-dimensional reconstruction uses a camera to photograph real-world objects and scenes, then processes them with computer vision techniques to obtain a three-dimensional model of the object. The main techniques involved include multi-view stereo, depth map estimation, point cloud processing, mesh reconstruction and optimization, texture mapping, Markov random fields, image segmentation, and more.