Qt Toolbox
1. rqt_console
(1) Return to the system and first launch the turtle example.
roscore
rosrun turtlesim turtlesim_node
rqt_console
The window above displays log output, including info messages, warnings, errors, and more.

(2) Run the keyboard control program.
rosrun turtlesim turtle_teleop_keyWhen the little turtle hits the boundary, the console outputs a warning.

2. rqt_plot
Close the rot_console console, then enter rqt_plot in the terminal.
Enter /turtle1/pose in the Topic field.
You can see all of the little turtle’s pose information being output.
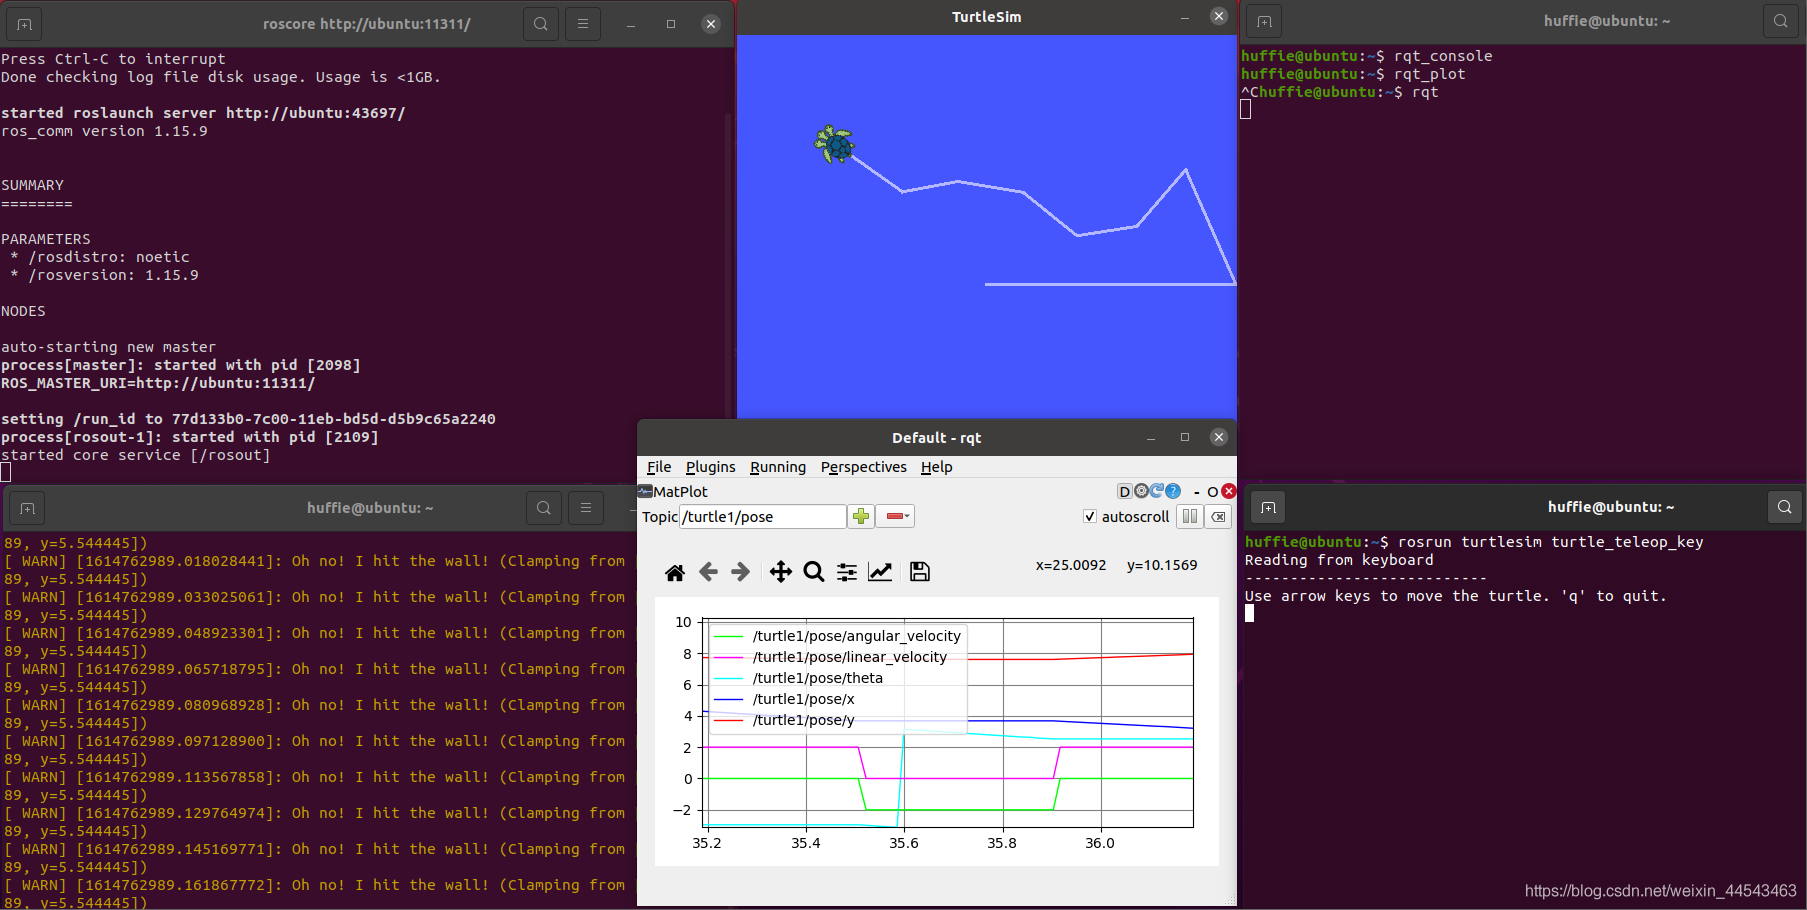
If it does not open, enter rqt in the terminal, then select plugin-visualization-plot to open it.
If “the core has already turned” appears: run
sudo apt-get install python-pipandpython -m pip install -U matplotlib.
3. rqt_image_view
rqt_image_viewA camera driver is required. The camera image is displayed here and is rendered after the image information is selected.
4. rqt
rqtThis integrates all rqt tools, and all plugins can be found under plugins.
Rviz
Enter the following on the command line:
roscore
rosrun rviz rviz
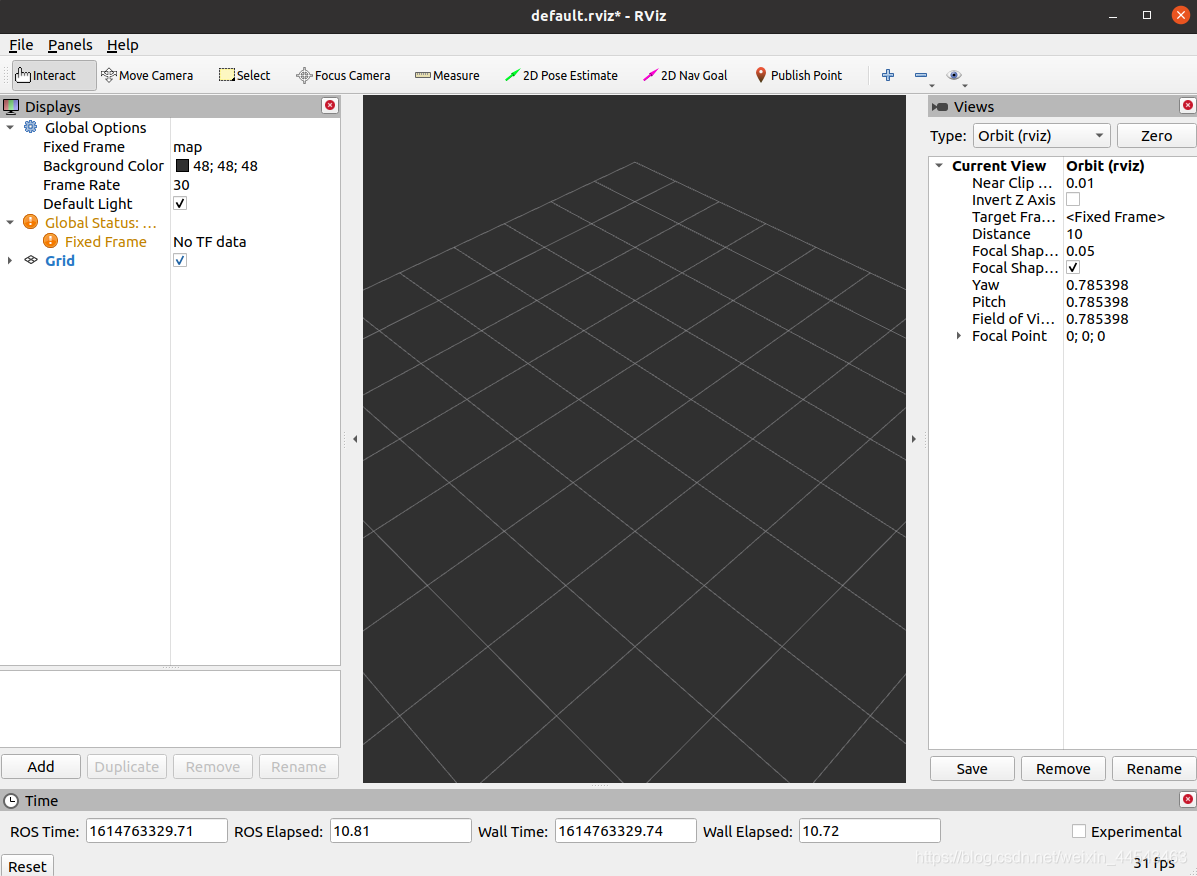
Rviz is a three-dimensional visualization tool that is highly compatible with robot platforms based on the ROS software framework.
- In Rviz, Extensible Markup Language (XML) can be used to describe properties such as the dimensions, mass, position, and material of robots, surrounding objects, and any other physical objects, and to display them in the interface.
- Rviz can graphically display robot sensor data, robot motion status, environmental information, and more.
The Rviz interface mainly includes a 3D view area, view settings area, toolbar, display list, and time display area.
Rviz is a data display platform, so a Topic must be selected when displaying data.
Gazebo
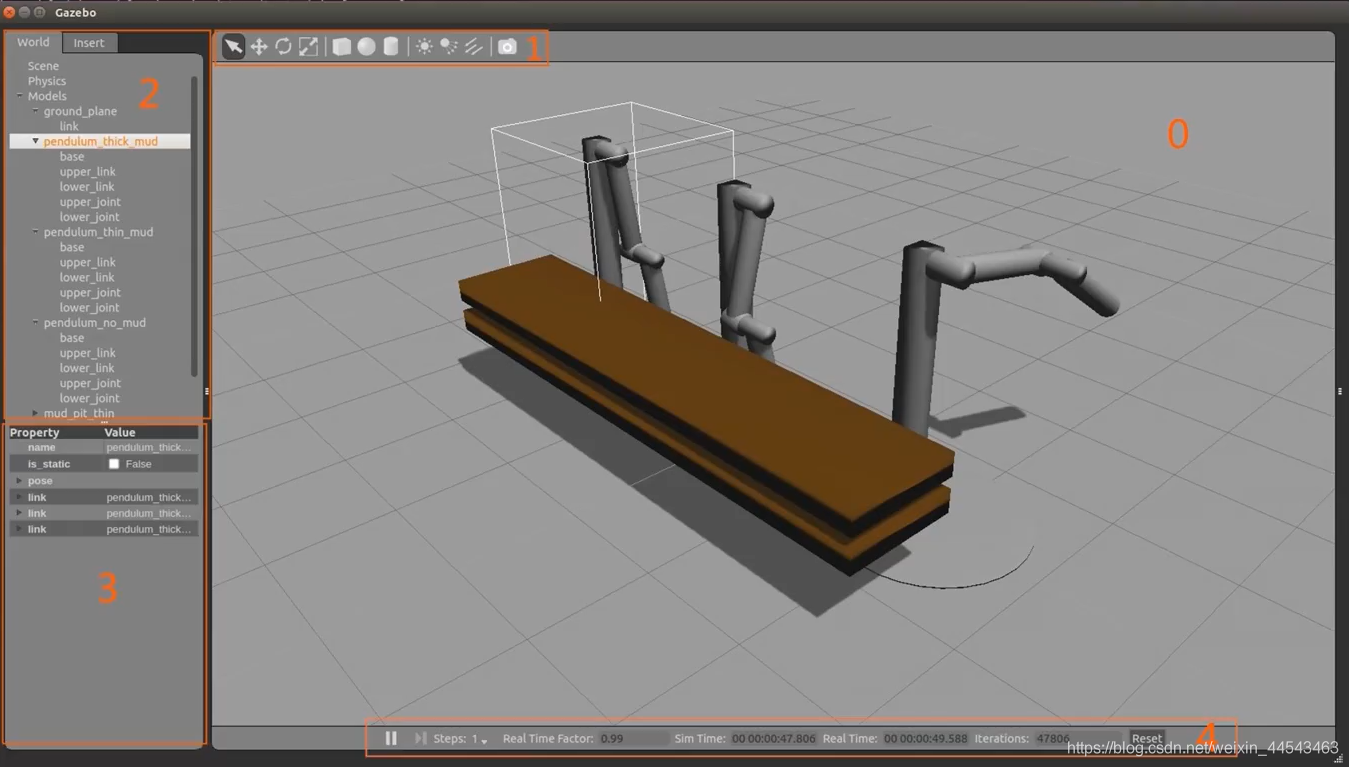
Gazebo is a powerful three-dimensional physical simulation platform used to simulate robots, sensors, and environments.
Gazebo also includes: 0-3D view area, 1-toolbar, 2-model list, 3-model properties, and 4-time display area.
roslaunch gazebo_ros willowIt may fail to run because Gazebo has high computer performance requirements, and the first load downloads some material packages, environments, and other resources from a remote server.
Comments