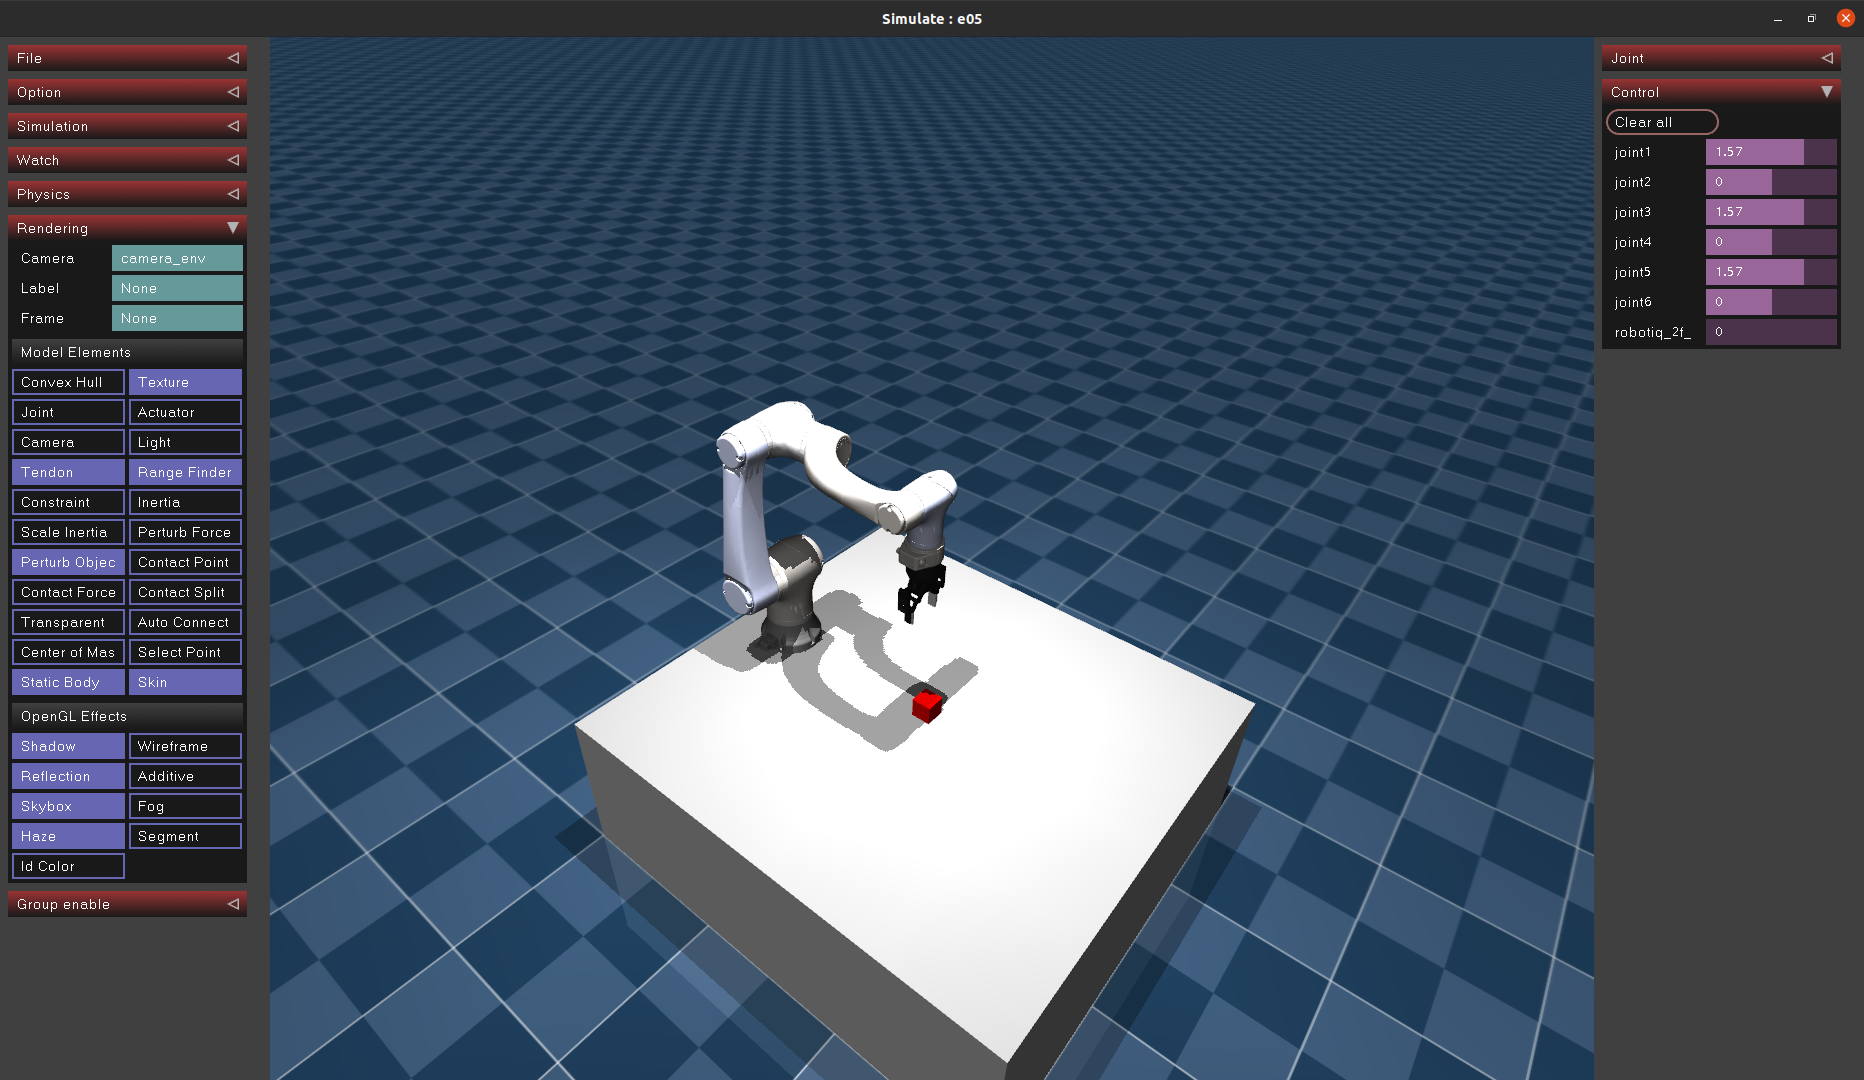
[Experiment Prep] Importing a Custom Robot into MuJoCo
Import a custom robot model into MuJoCo to lay the groundwork for building simulation environments for future reinforcement learning.
Notes on robotics, vision, and systems.
Import a custom robot model into MuJoCo to lay the groundwork for building simulation environments for future reinforcement learning.
An introduction to Markdown, the powerful note-taking syntax I have long used, and Obsidian, an editor based on Markdown syntax.
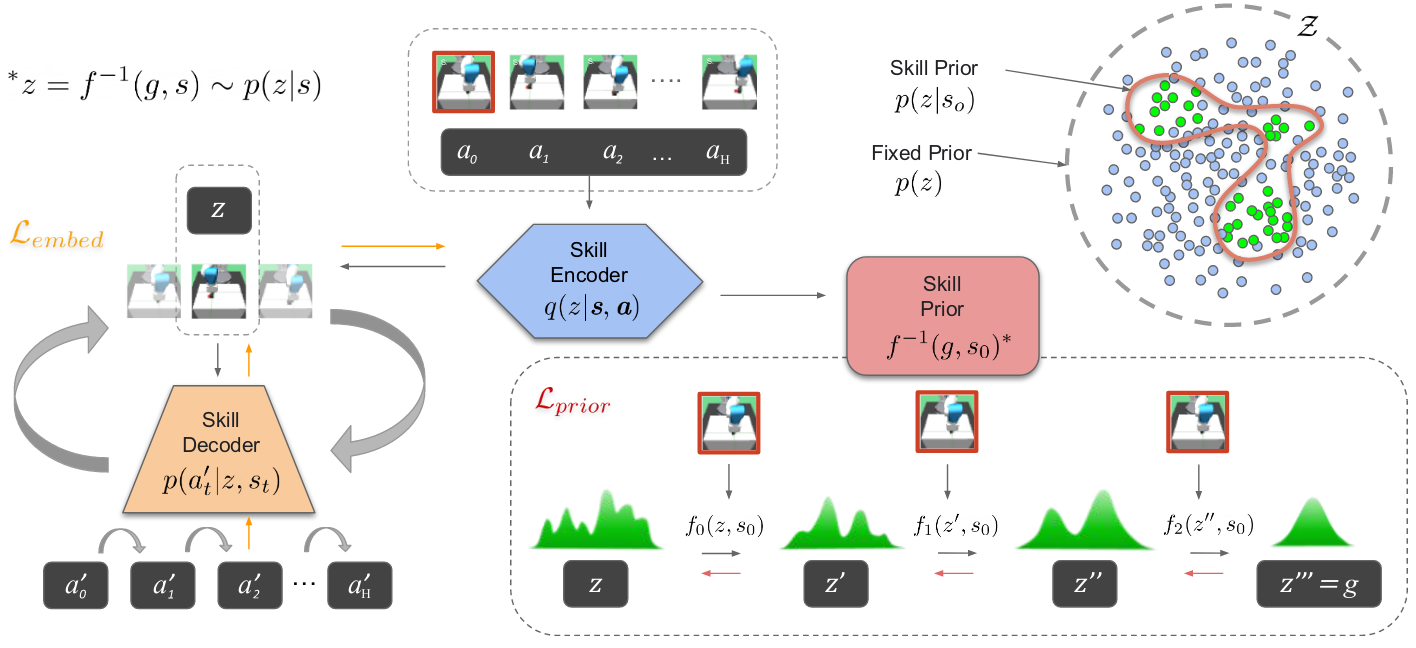
A skill-unit-based reinforcement learning method that decomposes tasks into skills, establishes mappings between skills and states, and learns a skill-selection policy
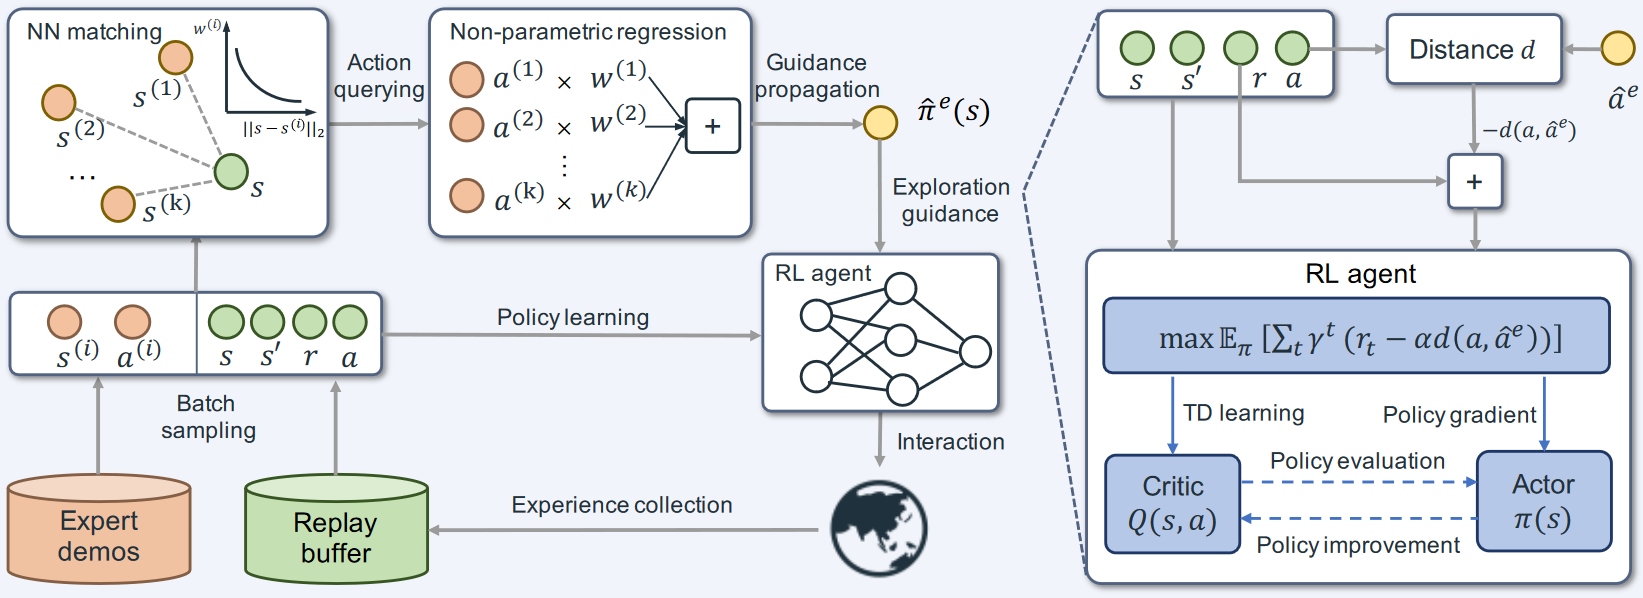
A surgical robot reinforcement learning method based on an improved DDPG+BC approach, developed by Yun-Hui Liu's team at The Chinese University of Hong Kong
A record of bugs that may occur while setting up reinforcement learning environments and running projects, along with their solutions
Survey and notes on reinforcement learning-based robot motion imitation methods.
A long-horizon imitation learning method from Fei-Fei Li's team at Stanford University that learns by watching human actions.
The most widely used point cloud library in C++
Instant-NGP, short for Instant Neural Graphics Primitives, uses multiresolution hash encoding to solve the efficiency problem encountered when parameterizing NeRF with a fully connected neural network. It greatly accelerates network training, reducing three-dimensional reconstruction time from several hours to several seconds.
A survey of research on methods for robot motion generation and planning learned from videos of humans grasping objects.