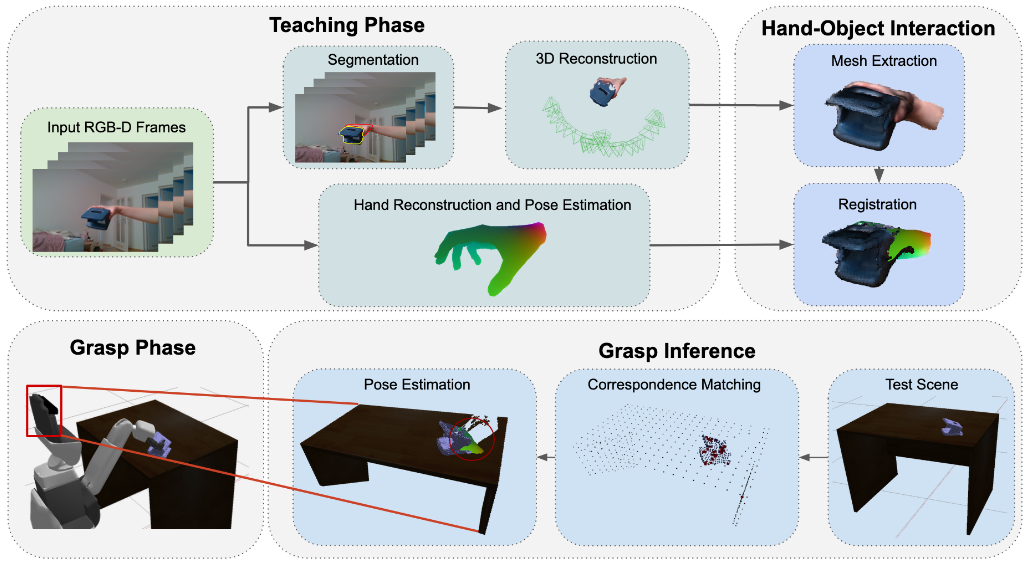
【Grasping by Imitation】Learning Robotic Grasping from Human Demonstrations
A survey of research on robotic grasping learned from videos of humans grasping objects.
Notes on robotics, vision, and systems.
A survey of research on robotic grasping learned from videos of humans grasping objects.
An introduction to a fundamental reinforcement learning algorithm, Proximal Policy Optimization (PPO)
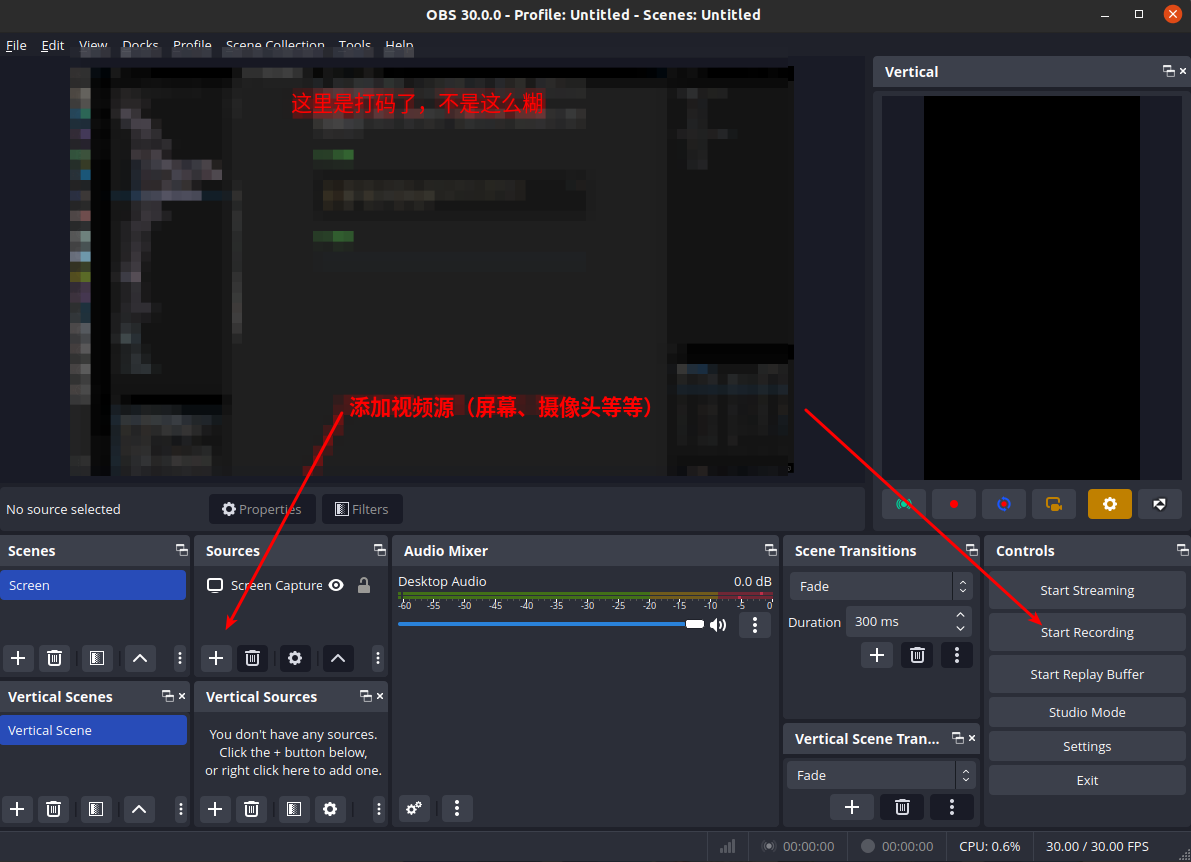
By default, Ubuntu can only take screenshots but cannot take screenshots, and the experience is very poor, so this article introduces two screenshot and screen recording tools I commonly use.
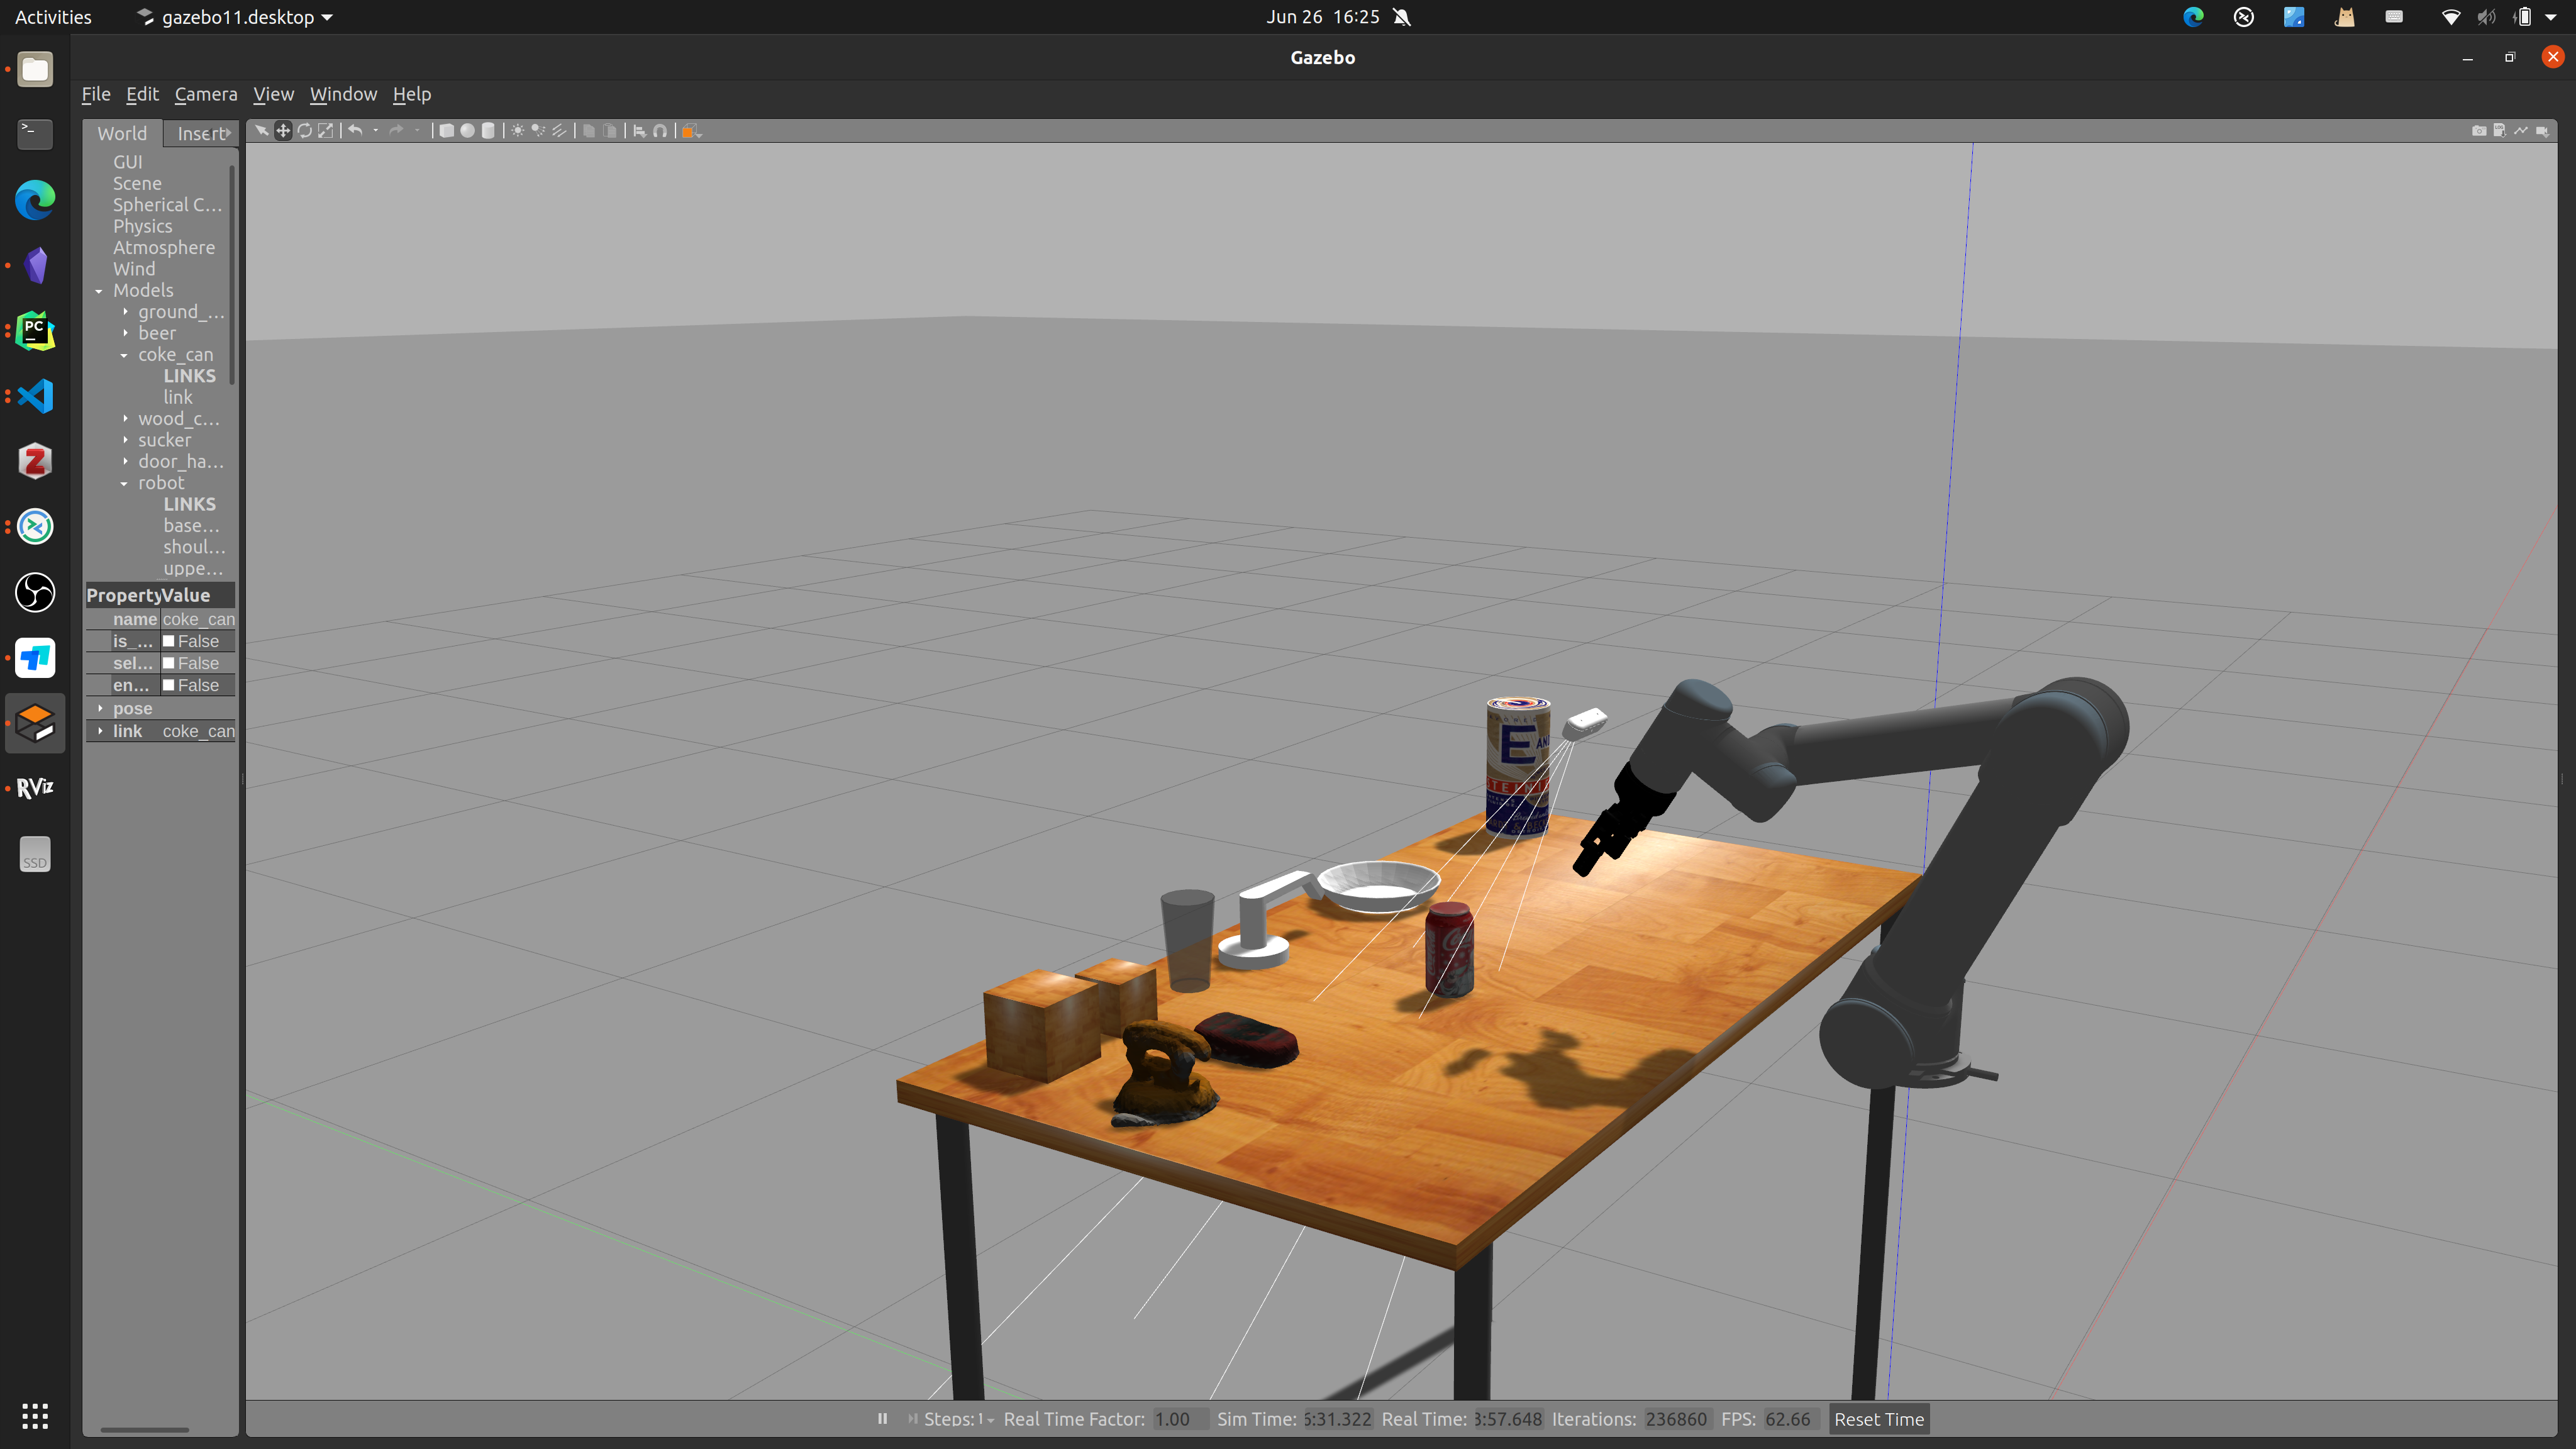
Build a 6D robotic arm simulation environment in Gazebo, add a camera, and implement a grasping simulation experiment.
A collection of various error messages encountered while using the ROS system for robot experiments, updated irregularly.
Using the classic YOLO algorithm for instance segmentation
Reproducing the RGB Matters algorithm proposed by Shanghai Jiao Tong University.
A survey of grasp pose estimation papers from top conferences and journals over the past three years
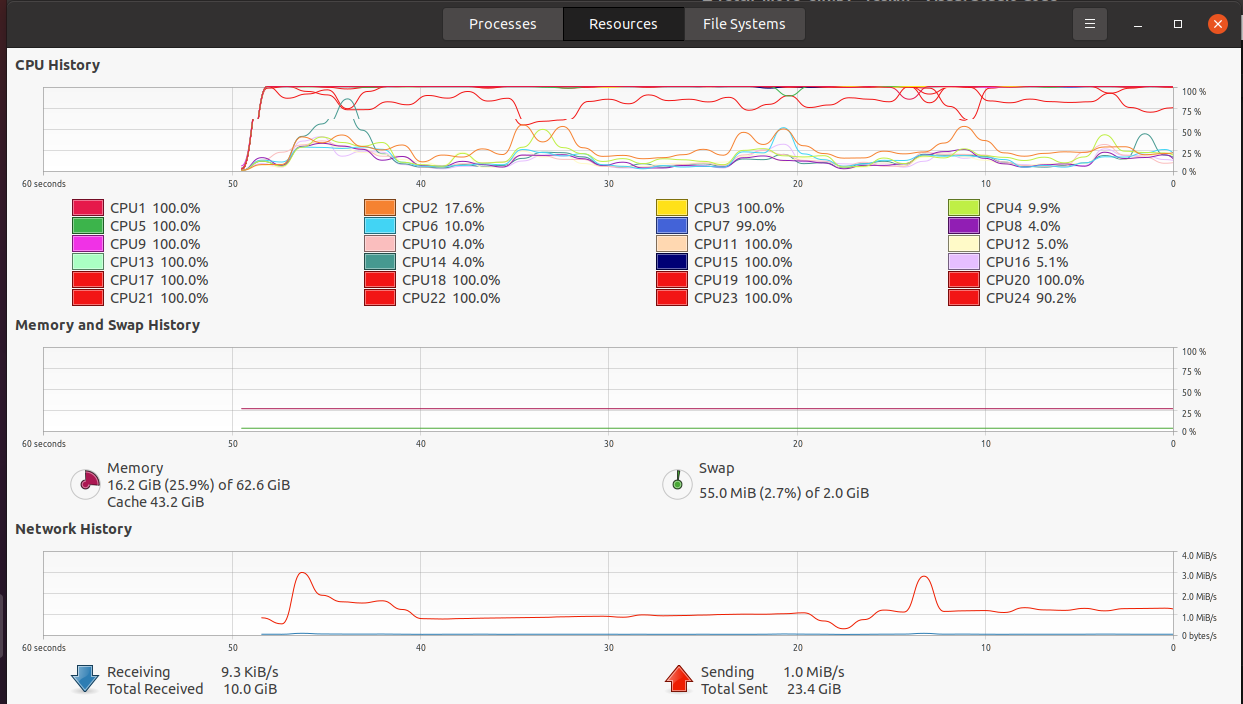
When running certain algorithms, you may sometimes need to check system resource usage to see whether the algorithm needs optimization or whether multithreading can be enabled. This requires checking the available system resources.
Reproducing Contact GraspNet, a grasp estimation algorithm proposed by NVIDIA