[6D Pose Estimation] Gen6D Algorithm
Algorithm reproduction
11 posts
Algorithm reproduction
Notes from searching for and reading ECCV papers related to 6D pose estimation from the past three years
A review of and notes on CVPR papers related to 6D pose estimation from the past three years
I searched for papers citing DenseFusion, but so many of them had no open-source code that after reading two, I switched to focusing only on papers from top-tier conferences.
I am currently studying 6D pose estimation algorithms. The LINEMOD dataset is the most commonly used dataset in this field, but testing only on an existing dataset is not enough. Building a custom dataset is necessary for practical applications.
FFB6D fuses RGB and point cloud information during the feature extraction stage, then performs instance segmentation and keypoint detection.
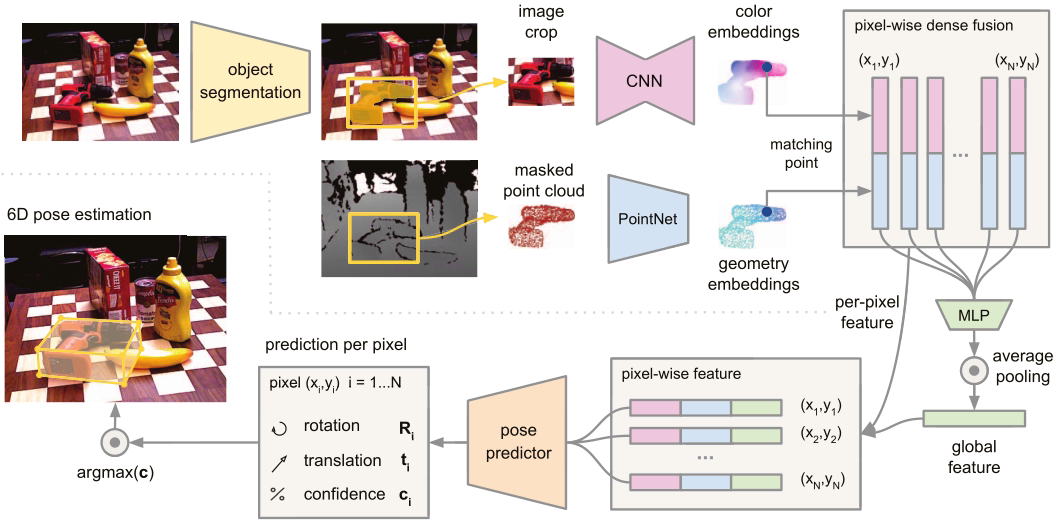
This paper proposes a heterogeneous architecture that processes two data sources (RGB and depth maps) separately and uses a novel dense fusion network to extract dense pixel-level features for pose estimation.
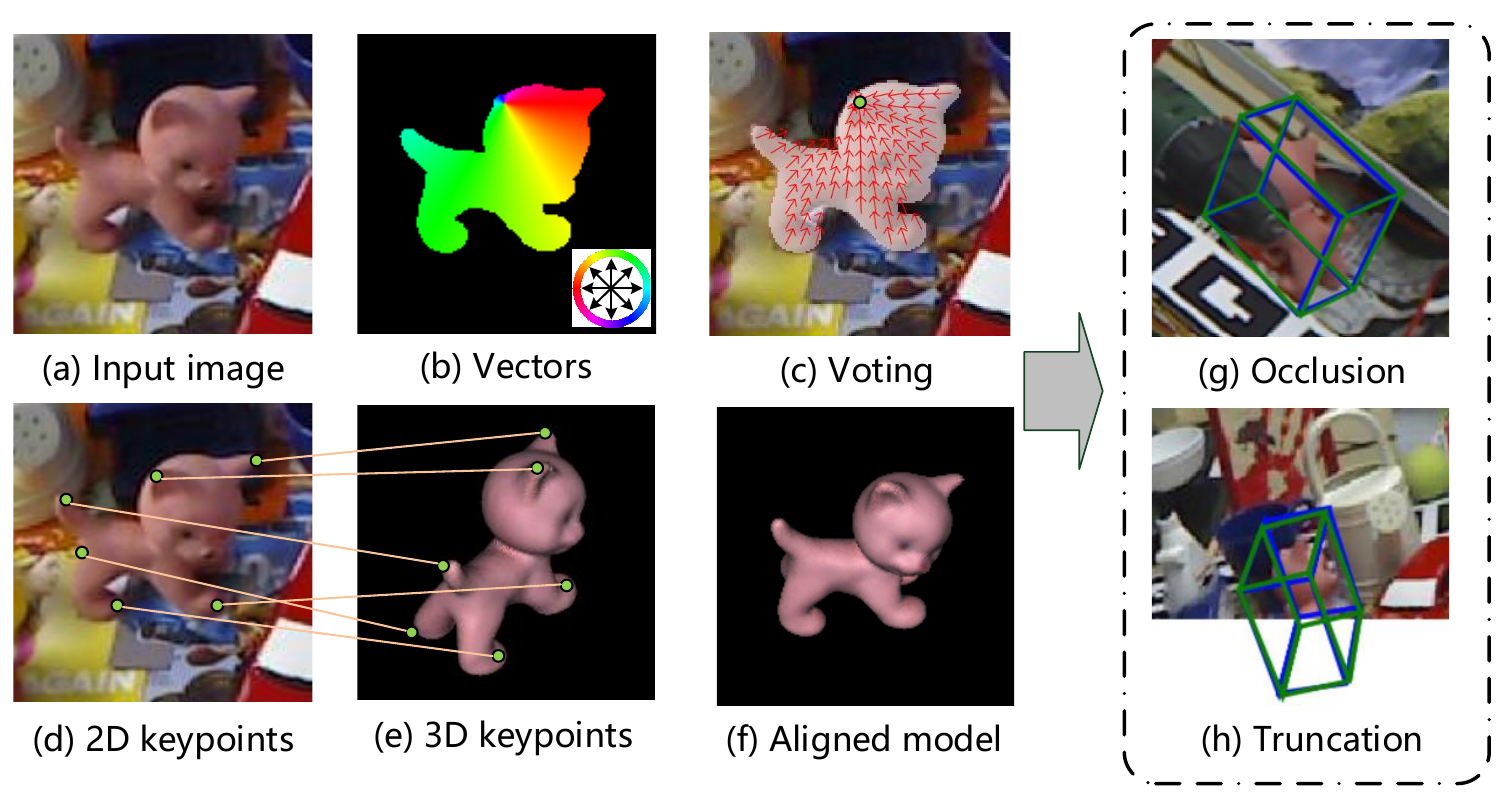
Attempted to test PVNet but gave up partway through.
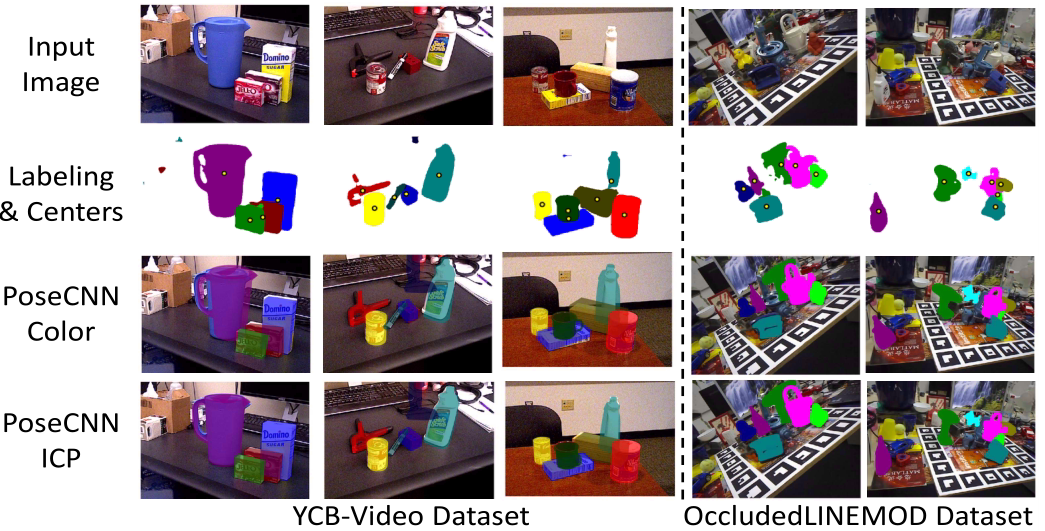
Addresses the increased difficulty of 6D pose estimation caused by occlusion and clutter between objects by combining a backbone network with ICP point matching.
The LineMod algorithm was proposed by Hinterstoisser et al. in 2011. Using template matching, it addresses real-time detection and 6D pose estimation and localization for low-texture three-dimensional objects in cluttered scenes.