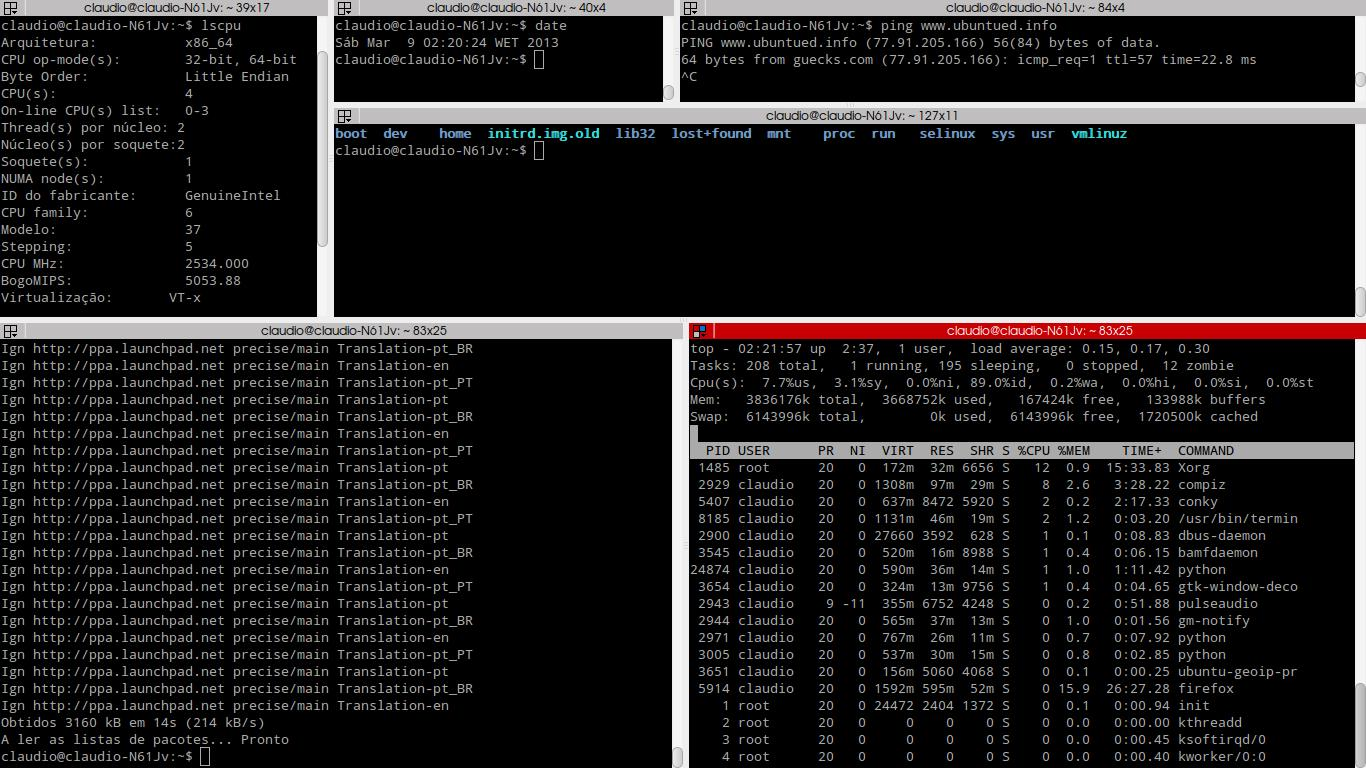
Common Keyboard Shortcuts for the Terminator Terminal Emulator
A handy terminal emulator.
Notes on robotics, vision, and systems.
A handy terminal emulator.
Environment setup can be tedious, and many programs' dependency environments can conflict with the local environment. Docker is a good way to avoid these issues.
Because some projects were developed some time ago, their programs use opencv2, while most people now have opencv4 installed. Since these projects contain a lot of code, modifying the source code would be too cumbersome, therefore considering installing multiple opencv versions side by side.
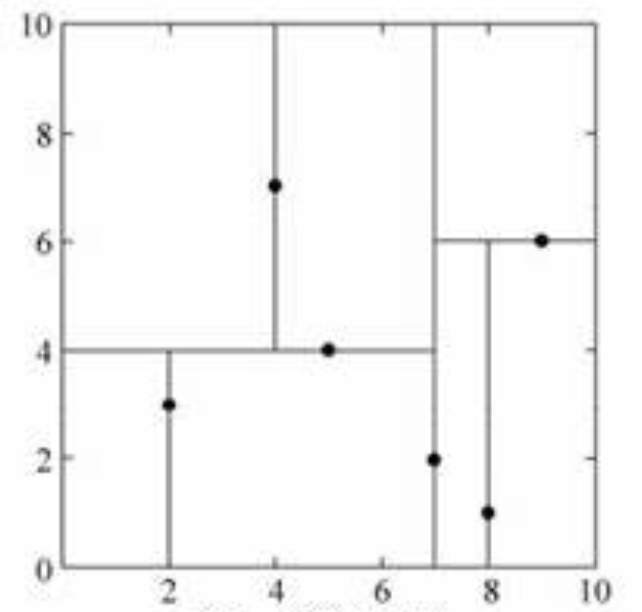
The nearest neighbors algorithm assumes a training dataset is given in which the class of each instance is known. For classification, a new instance is predicted from the classes of its k nearest training instances by majority voting or similar rules. Therefore, the k-nearest neighbors method has no explicit learning process.
I don't want to use remote desktop tools such as Sunlogin and ToDesk. My personal computer and the server are not on the same LAN, but I need remote access to the server, so I'm considering NAT traversal.
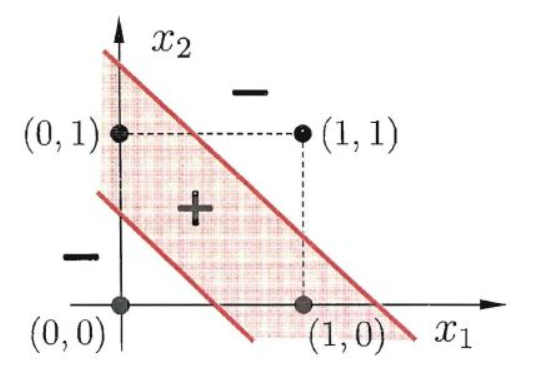
The perceptron is a linear binary classification model. Its input is an instance's feature vector, and its output is the instance's class. Its goal is to find a separating hyperplane that linearly divides the training data.
Statistical learning is the discipline in which computers build probabilistic and statistical models from data and use those models to predict and analyze data. These notes follow Li Hang's book *Statistical Learning Methods*.
I am currently studying 6D pose estimation algorithms. The LINEMOD dataset is the most commonly used dataset in this field, but testing only on an existing dataset is not enough. Building a custom dataset is necessary for practical applications.
FFB6D fuses RGB and point cloud information during the feature extraction stage, then performs instance segmentation and keypoint detection.
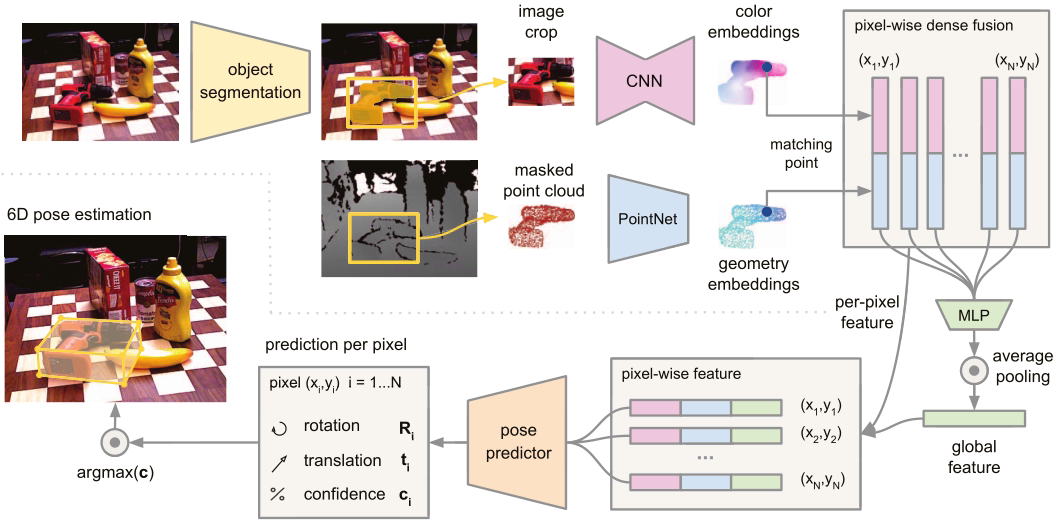
This paper proposes a heterogeneous architecture that processes two data sources (RGB and depth maps) separately and uses a novel dense fusion network to extract dense pixel-level features for pose estimation.